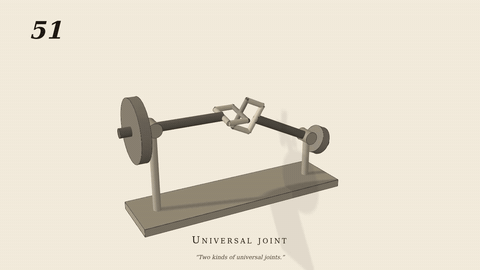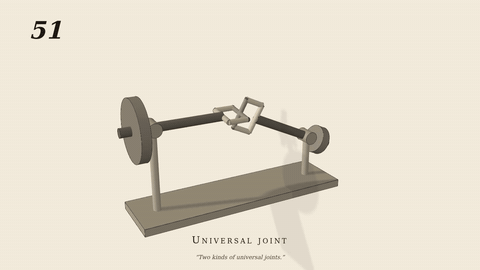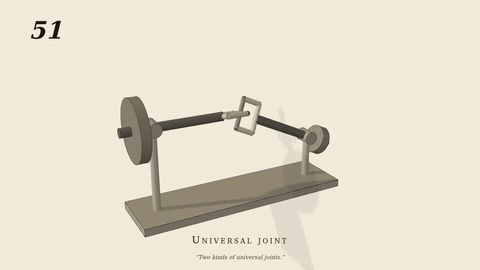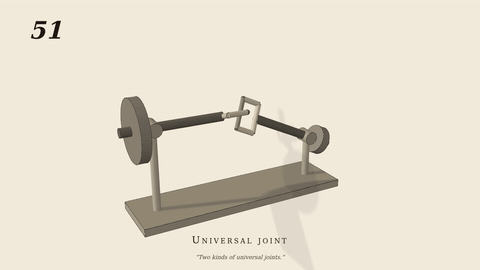
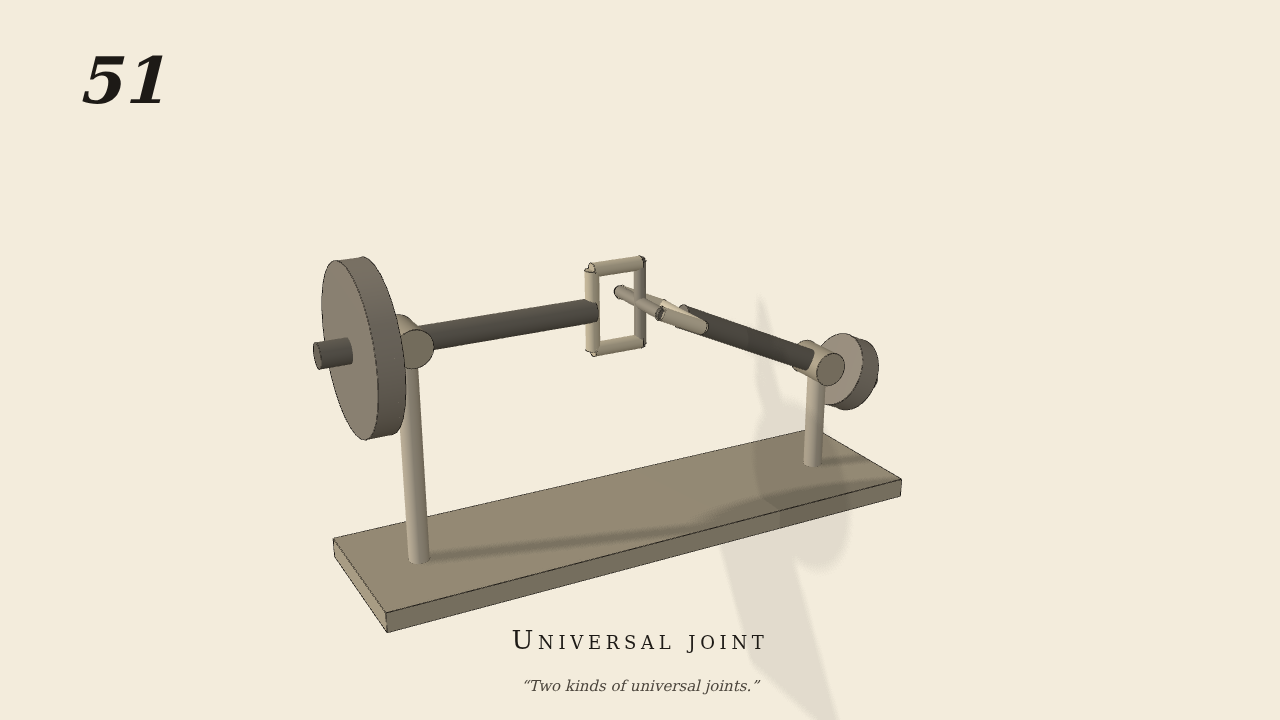
Two kinds of universal joints
50 and 51. Two kinds of universal joints.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- Brown's figure 51, the single joint: shaft A (driven, level, with its driving pulley) and shaft B (bent down 25°, a small pulley on it), each ending in a yoke; the cross turns in A's eyes (a hinge) and B's eyes are pins on its other arm ends
- Measured
- B/A 1.0010 over three turns; within each turn B's speed swings 0.909–1.101 of A's (Hooke: cos 25° = 0.906 to 1/cos 25° = 1.103), the cross rocks ±25.00° in A's eyes
- Notes
- Nothing couples the angles but the hinges and the two eye pins. Euler integrator (implicit and implicitfast lock up on the redundant eye pins at 1e-4). batch7/gen050.py single. Negative control: yoke eyes off the cross → B stands (0.0000).
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)