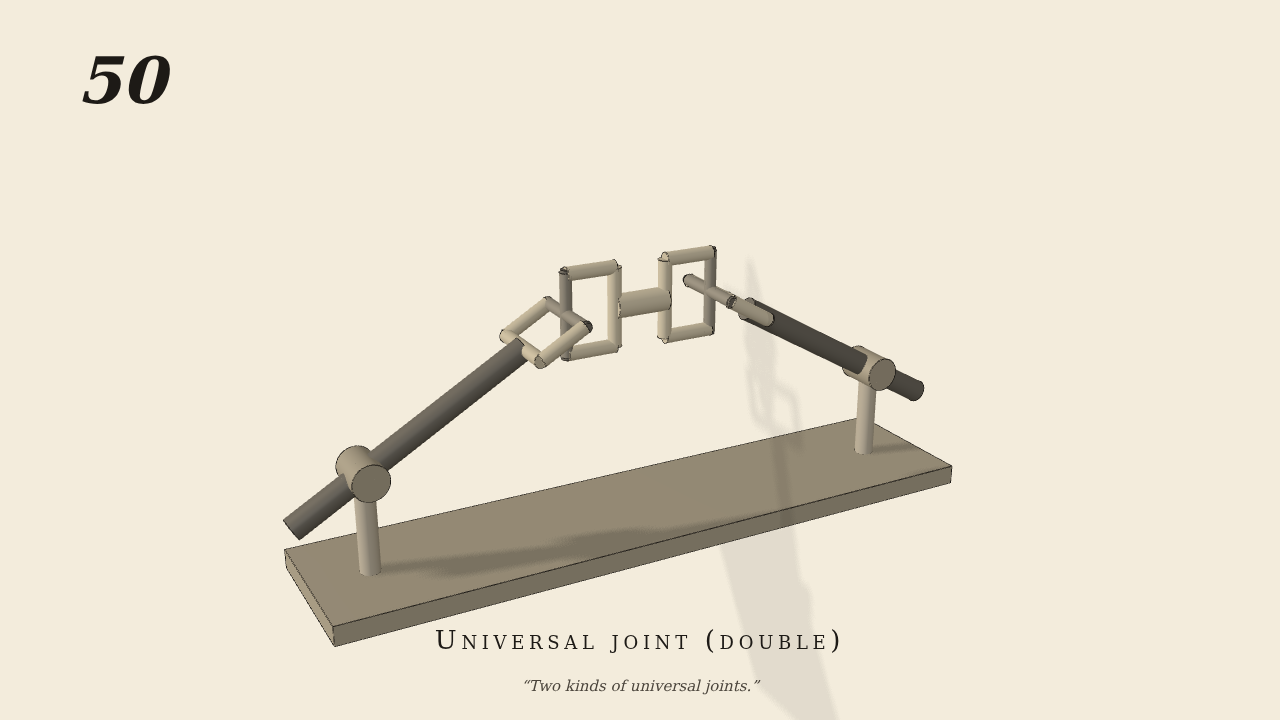
Two kinds of universal joints
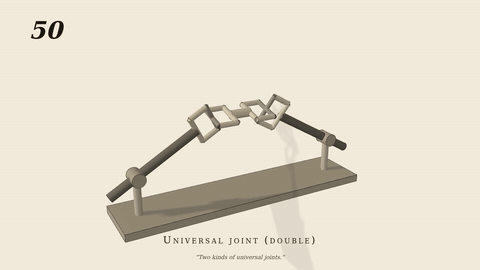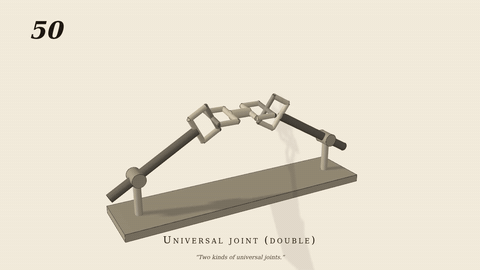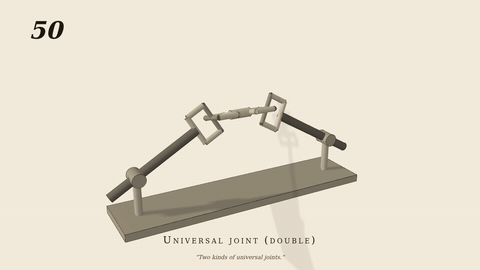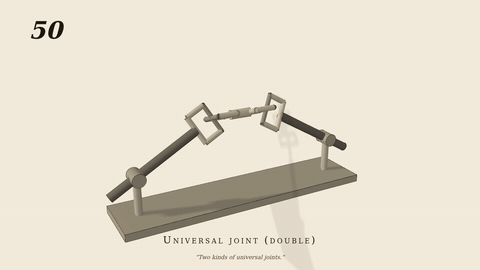
50 and 51. Two kinds of universal joints.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- Brown's figure 50, the double joint: shaft A (driven) and shaft B, each 30° from a middle link, each ending in a yoke; a cross between each shaft's yoke and the middle link's yoke turns in the eyes of both (hinges), B's eyes are pins on the second cross's arm ends; the middle link's two yokes are in phase
- Measured
- B/A 1.0000 (48 slices 0.9999–1.0001: the second joint undoes the first), each cross rocks ±30.00° in its eyes
- Notes
- Nothing couples the angles but the hinges and the two eye pins (no gears, no contacts). timestep 1e-4: the light crosses on the pins lock up at 5e-4. batch7/gen050.py double. Negative controls: yoke eyes off the cross → B stands (0.0000); middle link's yokes a quarter turn apart → B swings 0.754–1.321 of A's speed (cos²30°–1/cos²30°).
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)