Uniform into variable rotary motion
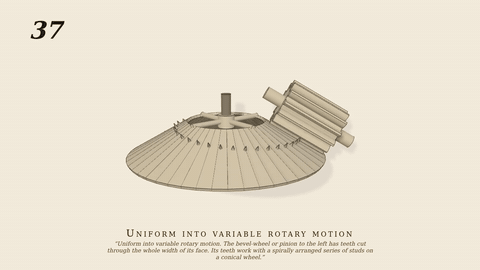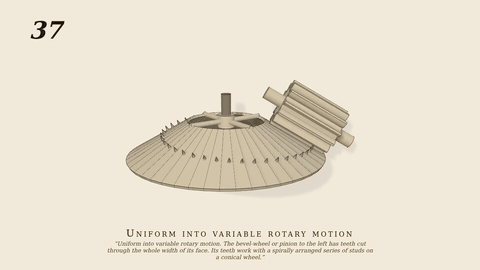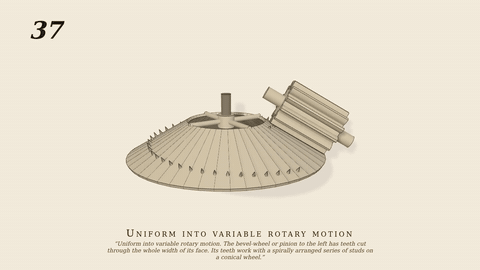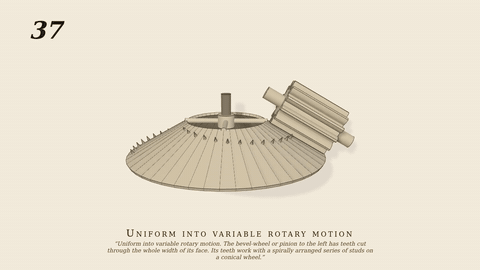
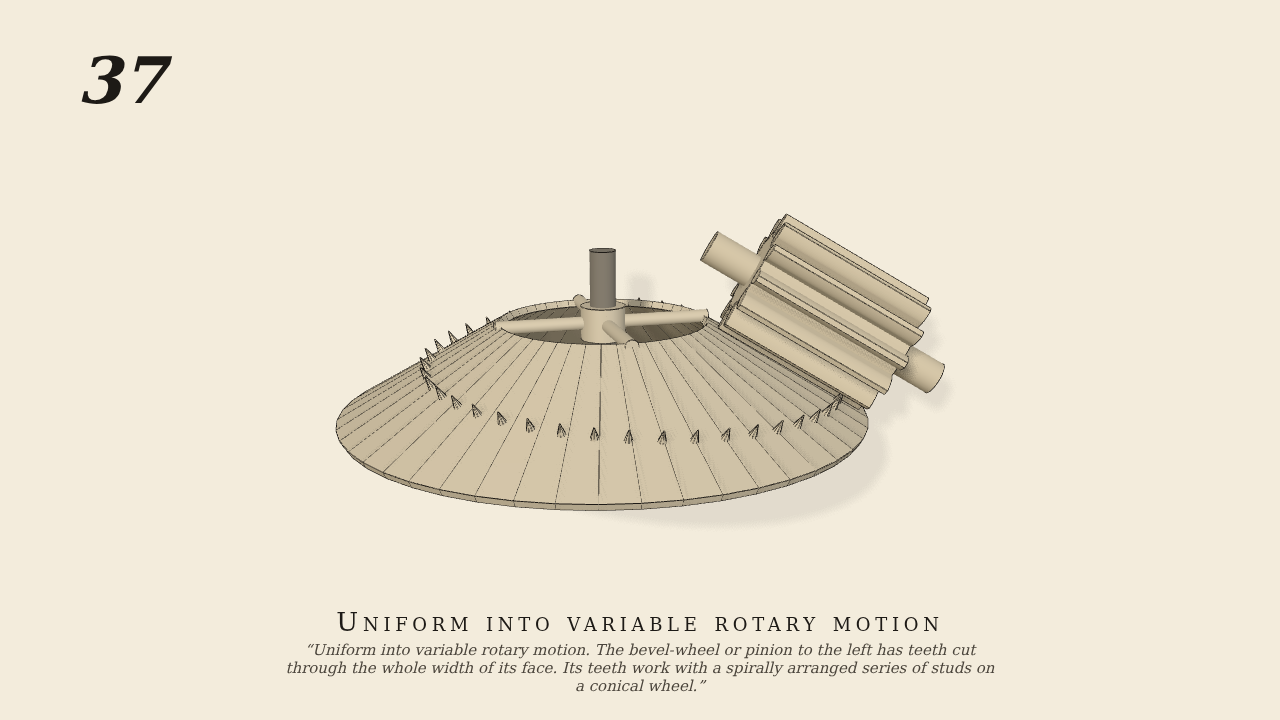
Uniform into variable rotary motion. The bevel-wheel or pinion to the left has teeth cut through the whole width of its face. Its teeth work with a spirally arranged series of studs on a conical wheel.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- a conical wheel (face at 60 deg, r 6..14) on an upright shaft with 39 pointed studs in one spiral turn (one pinion pitch apart at each radius); a 12-tooth pinion with teeth through its whole 8.8 width lies along the slope
- Measured
- slice means of ω_wheel/ω_pinion fall 0.43 → 0.19 as the spiral runs outward (r_p/r: 0.43 → 0.22), then jump back as the inner end is taken up; mean 0.29
- Notes
- Only the pinion is motor-driven (30 rpm, the way that runs the spiral outward: the other way the fast wheel overtakes the teeth at the hand-over and jams). The wheel coasts across the spiral's 0.36 rad gap; pointed studs (and two short first studs) let a tooth tip that lands on one slide off (flat tops jammed in 1 of 6 perturbed runs). Negative control: studs out of contact → the wheel stands (0.0000).
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)