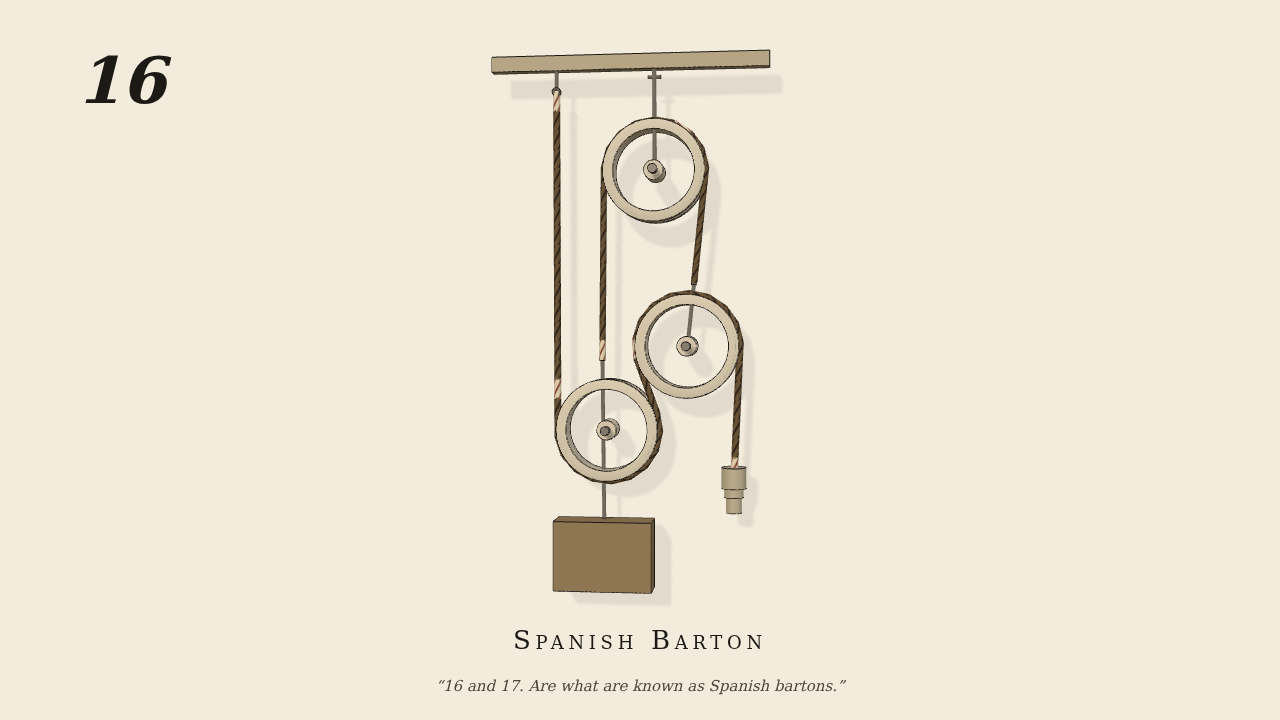
Spanish bartons
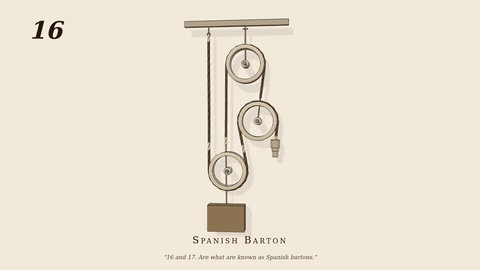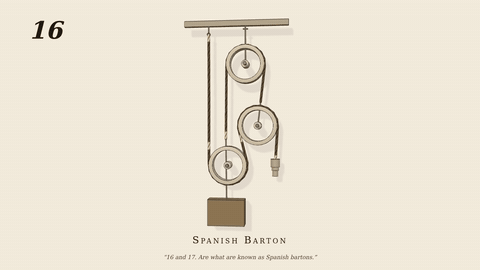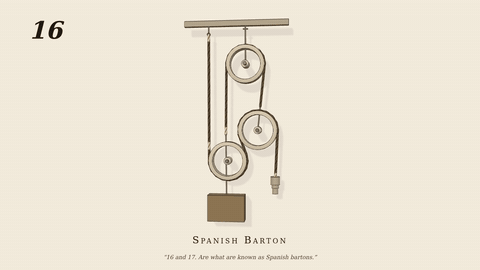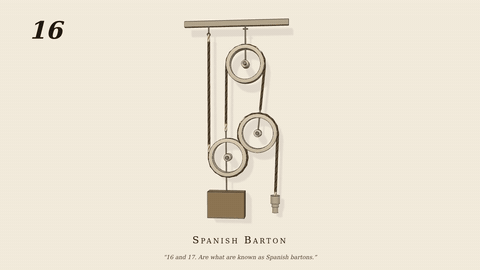
16 and 17. Are what are known as Spanish bartons.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- two ropes of links (friction on the sheaves): the fall, 46 hemp links, hooked to the ceiling, under C, over B and down to the hand; the strop, 24 links, from C's eye over the fixed sheave A to B's eye
- Measured
- load/hand 0.258 (4 parts of fall buy 1 of rise), B/hand −0.255, sheaves A 3.20, C −3.20, B 9.18 rad/m (fall speeds: 3.23, −3.21, 9.53), hand's pull 43.5 N against the quarter-weight's 40.7 N (bearing friction the rest), pen ≤ 0.05 mm
- Notes
- Only the hand is driven (a slide in a guide along the fall, 6 cm/s). Each moving sheave turns on its own pin (`spin`) and its hook hangs free on the same pin, so the fall rolls on the rims instead of sliding (with the hooks sprung to the sheaves they locked, and the pull came out 100 N). Negative control: the fall's contact with the sheaves off → the weight does not rise (0.000; it drops 1 cm to its stop while the hand still hauls).
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)