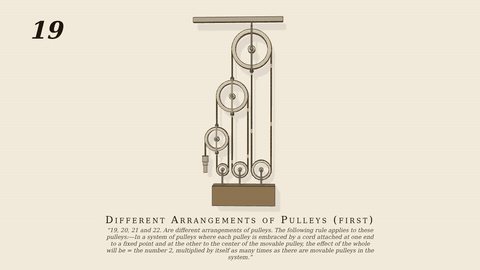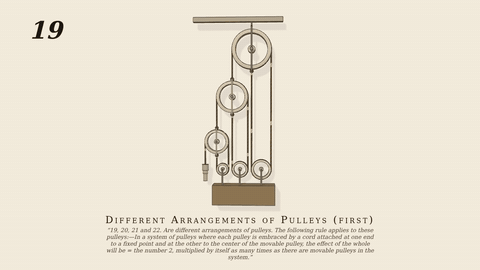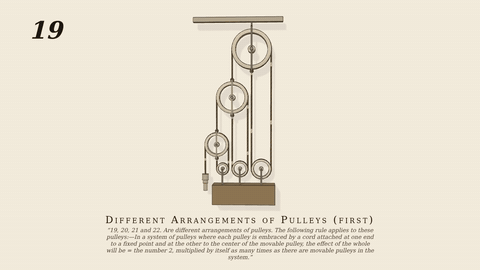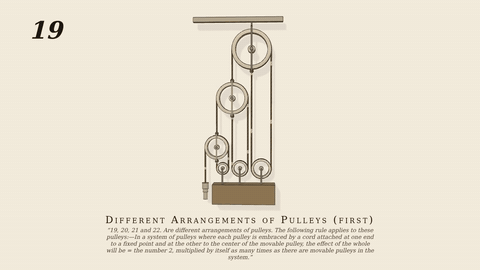
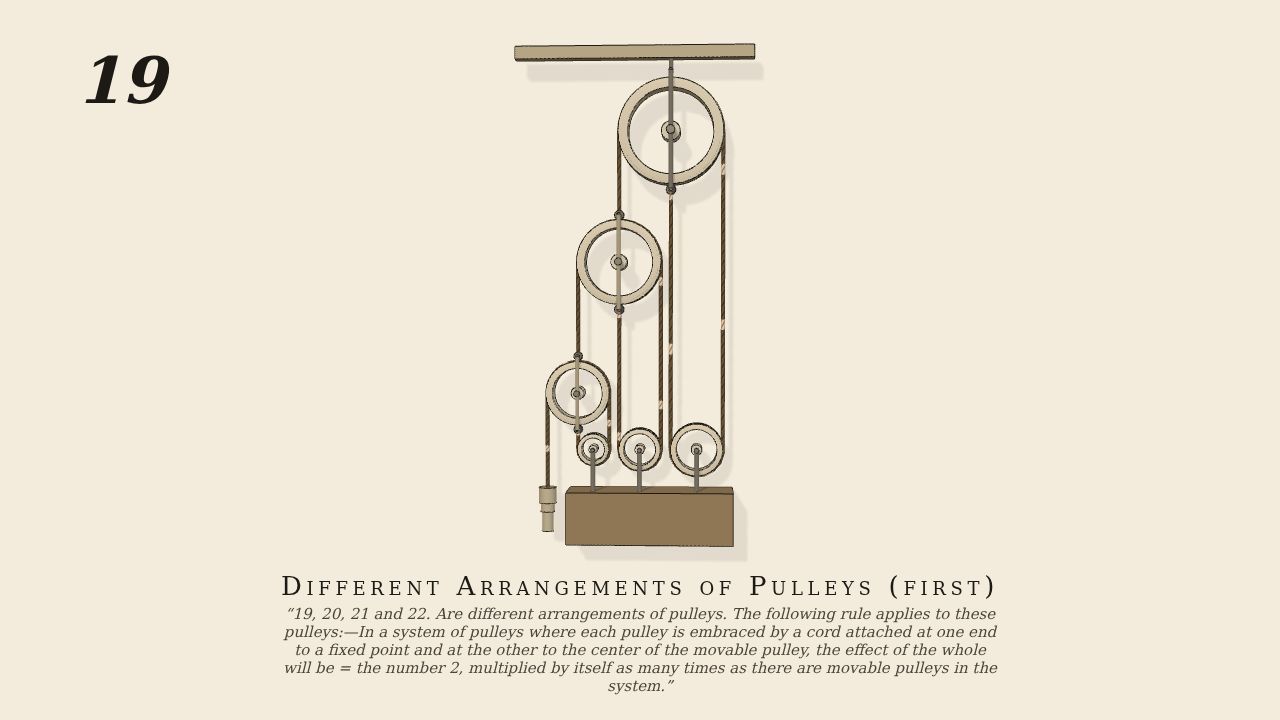
Different arrangements of pulleys
19, 20, 21 and 22. Are different arrangements of pulleys. The following rule applies to these pulleys:—In a system of pulleys where each pulley is embraced by a cord attached at one end to a fixed point and at the other to the center of the movable pulley, the effect of the whole will be = the number 2, multiplied by itself as many times as there are movable pulleys in the system.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- three ropes of links (friction on the sheaves), each made fast at one sheave's pin, under a sheave on the weight, back up over the first sheave and down to the next block's pin: rope 1 (88 links) A's pin → w3 → A → B; rope 2 (75) B → w2 → B → C; rope 3 (53) C → w1 → C → the hand
- Measured
- weight/hand 0.0401 (26 parts: the hand pays out 3 × 8 + 2 = 26 for 1 of rise), B/hand −0.0763, C/hand −0.307, sheaves A −0.78, w3 −0.79, B −2.88, w2 −2.86, C −11.53, w1 −11.44 rad/m (strand speeds: 0.769, 0.769, 2.885, 2.885, 11.54, 11.54), pull 12.2 N against (W − 8 W_C − 2 W_B)/26 plus guide drag less the hand's weight 12.1 N, pen ≤ 0.07 mm
- Notes
- Only the hand is driven (a slide in a plumb guide on rope 3's hauling part, 6 cm/s). Shared plate 19–22. Ropes end at eyes on straps in front of each sheave, just outside the rim on the pin's vertical (the plate draws them at the pins). The weight's guide has a dashpot (2000 N s/m) to still its bounce on the ropes' stretch. Negative control: all three ropes' contact switched off → the weight does not rise (0.000; it drops to its stop while the hand still hauls; run at dt 1e-5).
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)