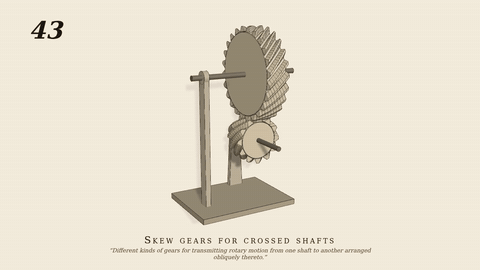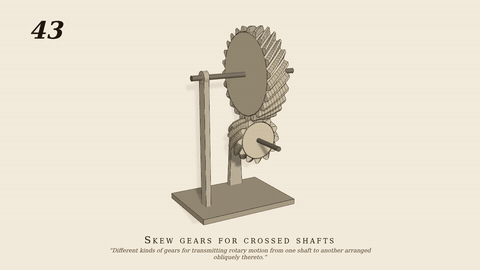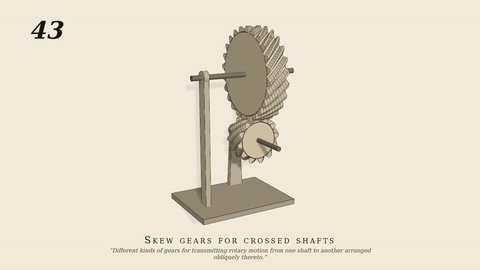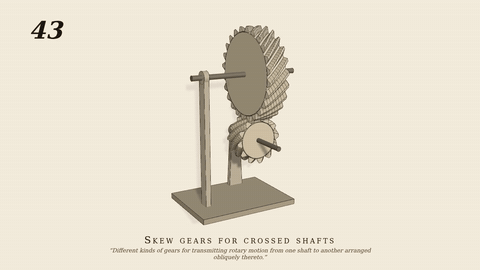
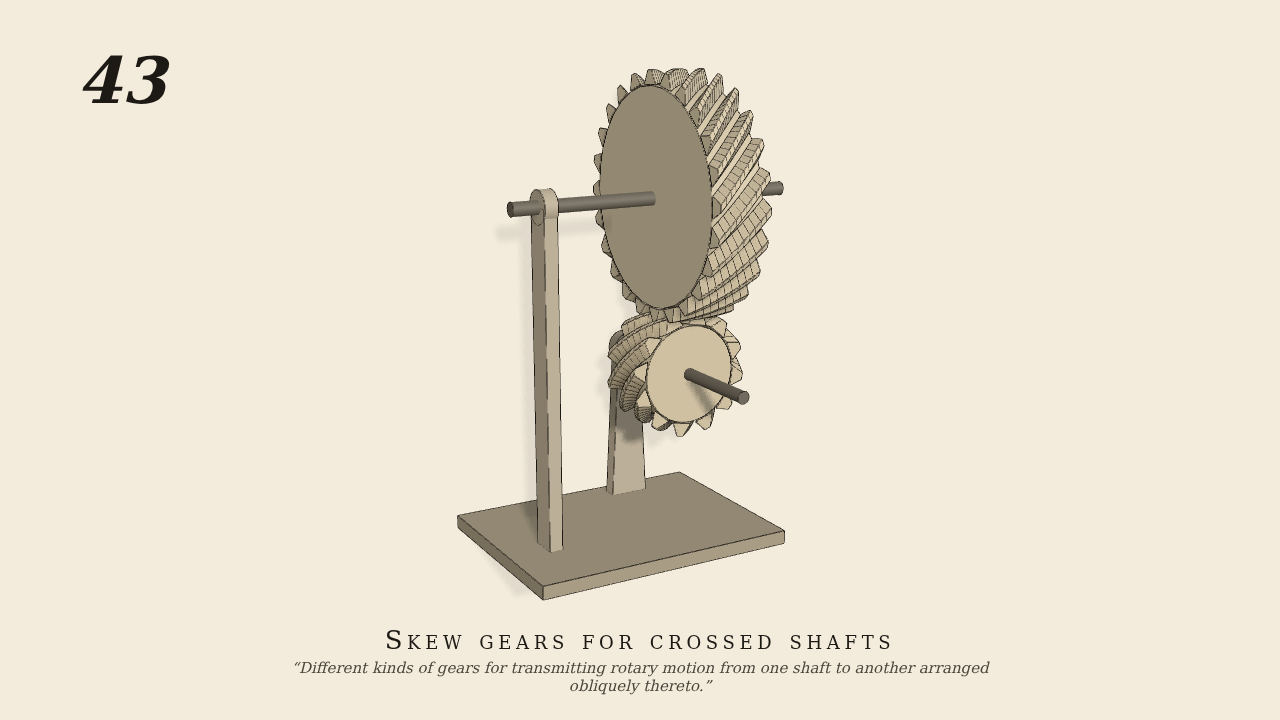
Skew gears for crossed shafts
42 and 43. Different kinds of gears for transmitting rotary motion from one shaft to another arranged obliquely thereto.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- shafts crossing at right angles without meeting (12.73 apart): a 12-tooth and a 24-tooth gear, teeth oblique at 45° and the same hand on both (normal module 0.5, pitch radii 4.24 and 8.49), each tooth ten twisting straight-flanked segments
- Measured
- −0.5000 (ideal −12/24)
- Notes
- shared plate 42–43; the plate's second form is read as skew (crossed oblique-tooth) gears, after No. 42's bevels. Point contact swept across the teeth. Only the 12-tooth shaft is motor-driven. Robust in 6 perturbed runs. Negative control: the driver's teeth out of contact → the crossed shaft stands (0.0000).
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)