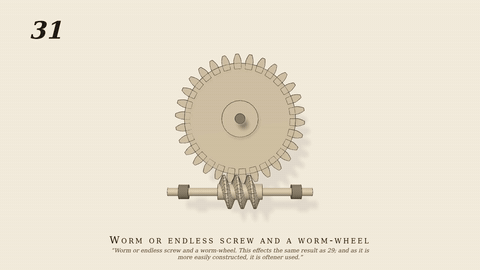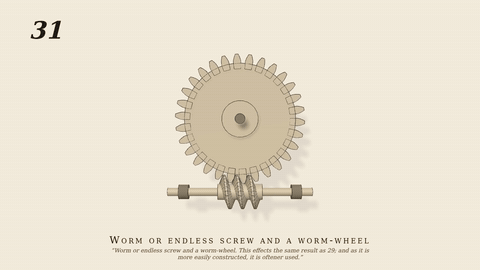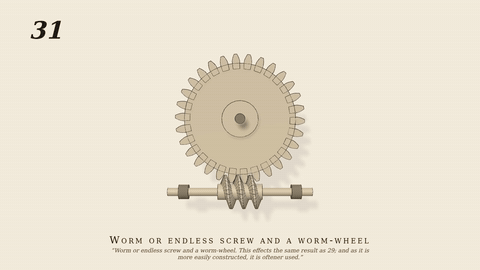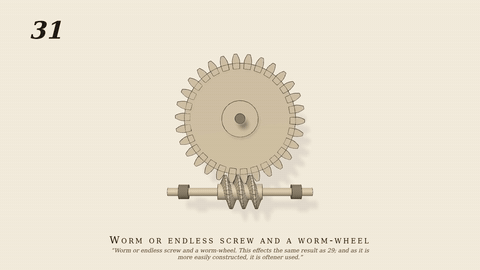
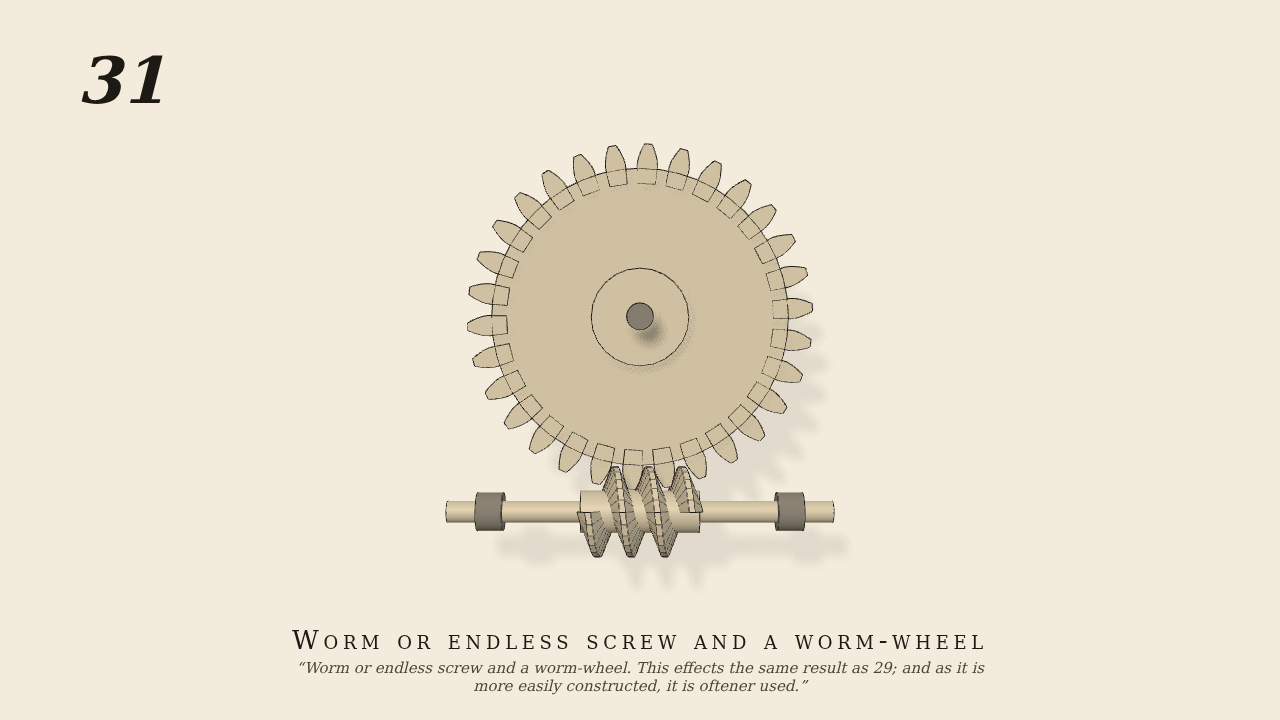
Worm or endless screw and a worm-wheel
Worm or endless screw and a worm-wheel. This effects the same result as 29; and as it is more easily constructed, it is oftener used.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- a single right-hand worm (3 turns, pitch radius 1.6, axial pitch 1.571 = π·0.5) as 72 convex thread segments under a 30-tooth wheel of module 0.5, axes at right angles
- Measured
- ω_wheel/ω_worm = 0.0333 (1/30: one tooth per worm turn; frictionless 0.033)
- Notes
- Only the worm is motor-driven (60 rpm). Negative control: thread out of contact → the wheel stands (0.0000). New: part piece `loft` (a convex solid between two sections: the thread segments, drawn and weighed exactly); the wheel uses spur `meets_parts`.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)