Horizontal overshot water-wheel
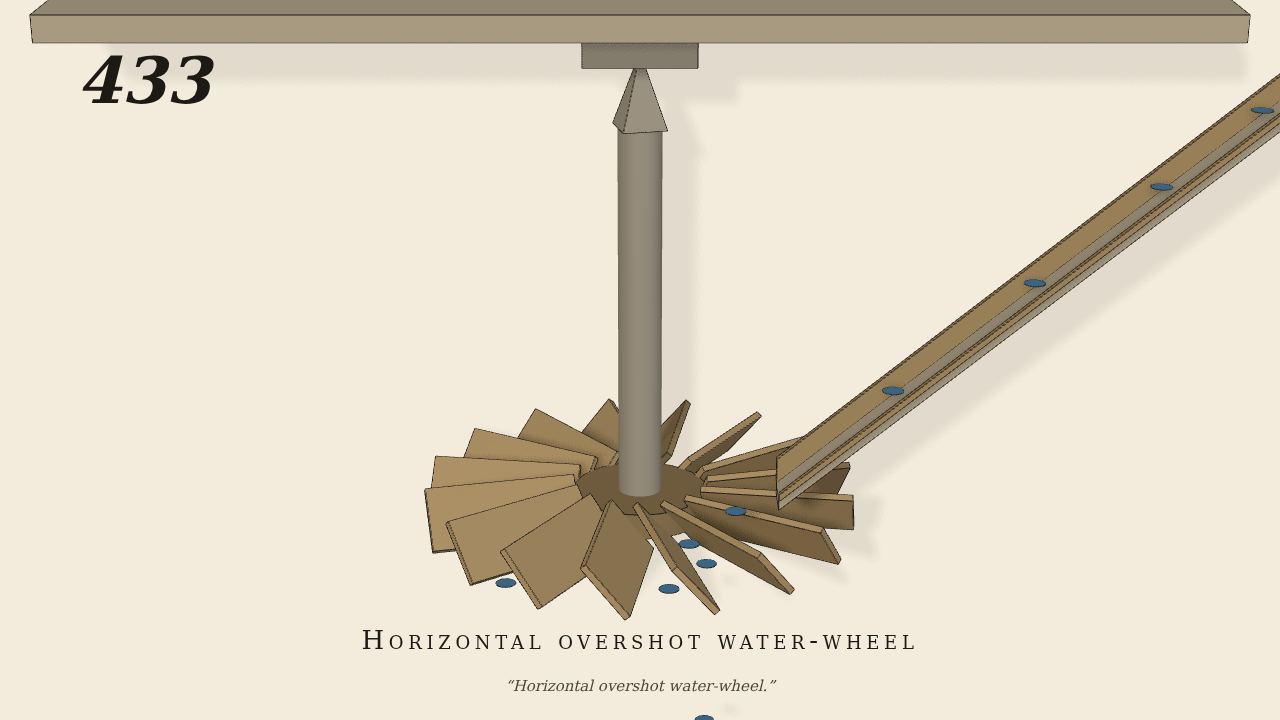
Horizontal overshot water-wheel.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- Brown's view, from a little above, gravity on. A wheel turns on an upright shaft whose point runs in a bearing under a beam. It has 16 flat floats on a collar, reaching from 3 cm to 10 cm out and 3 cm deep, each leaning 40 degrees so that its face slopes away from the oncoming water. A trough on the right, open on top with a low near side so the water shows, slopes down at 40 degrees to a spout just above the near floats. The water is 220 parcels, each a smooth ball 0.9 cm across at 1 g/cm³. They start at rest along a smooth, nearly level feeder 22 cm above the spout, spread along it so that they reach the trough at a steady rate from 0.2 s to 9.5 s. Each parcel moves freely in three directions on three slides. It touches the trough and the floats but not other parcels, and falls away below the wheel. The water is the only input. Nothing is driven (there is a zero-torque driver), and the shaft works against a load (0.0004 N m s).
- Measured
- The first water strikes the floats at about 0.9 s, coming off the spout at about 2 m/s. From rest the wheel turns clockwise seen from above and settles at about 3 rad/s (28 rev/min) while the water runs, never running back. Each parcel strikes a leaning float, runs down its face and drops away below. Contact penetration stays within 2.4 mm.
- Notes
- The water is modelled as separate parcels that do not touch one another. They are released from rest along a long, nearly level feeder out of the picture rather than supplied continuously, and they fall out of the picture below the wheel instead of into a tail-race. The bearing at the foot of the shaft is left out; the shaft hangs from its upper bearing.
Film (MP4) · Still (PNG) · Spec (YAML) · Model (MJCF)