Overshot water-wheel
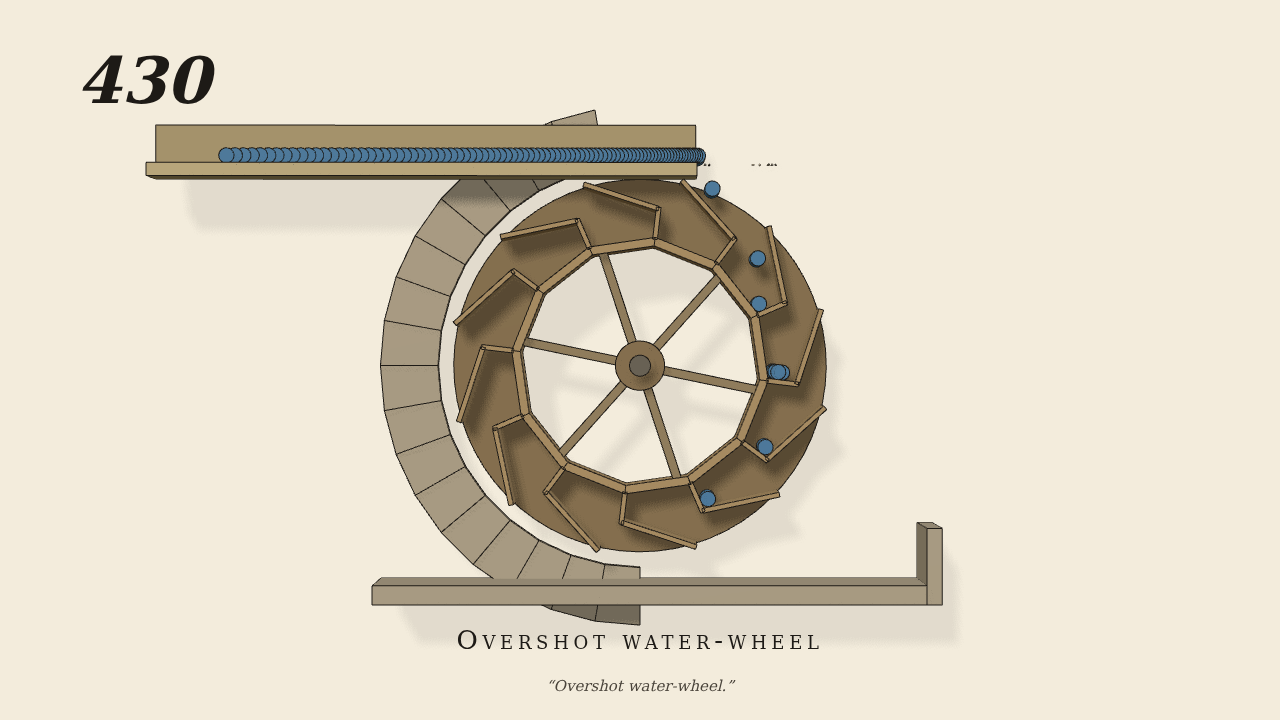
Overshot water-wheel.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- Brown's side view, gravity on, the wheel's near shroud left off to show the buckets. A wooden wheel 20 cm across on its axle, with 12 buckets between the sole (6.8 cm) and the outside: each bucket's board stands out from the sole and its wrist bends back against the rotation, so the buckets on the descending side hold their water and empty near the bottom. The water is 116 round parcels (0.8 cm across, 1 g/cm³) lying at rest in a smooth flume that falls very slightly towards the wheel, spread along it so that they pour over the lip at a steady rate from 0.2 s to 9.5 s, into the buckets just past the top. Each parcel moves freely in the plane of the wheel (two slides), touching the flume and the buckets but not other parcels, and spills into the tail-race. The water's weight is the only input; nothing is driven (a zero-torque driver), and the shaft works against a load.
- Measured
- The first water reaches the buckets at about 0.5 s and the wheel starts from rest, turning clockwise (Brown's arrow) and settling at about 1.3 rad/s (12 rev/min) while the water runs, never running back; the loaded buckets carry their water down the descending side and empty near the bottom into the tail-race. Contact penetration stays within 1.3 mm (falling water on the boards).
- Notes
- The near shroud is left off (Brown draws it, with the buckets dotted behind it) and the pit's masonry is drawn without hatching; water is modelled as separate round parcels that do not touch one another (they can overlap in a bucket), released from rest along a long, nearly level flume rather than supplied continuously from a head-race; the parcels that spill keep moving along the tail-race until its end.
Film (MP4) · Still (PNG) · Spec (YAML) · Model (MJCF)