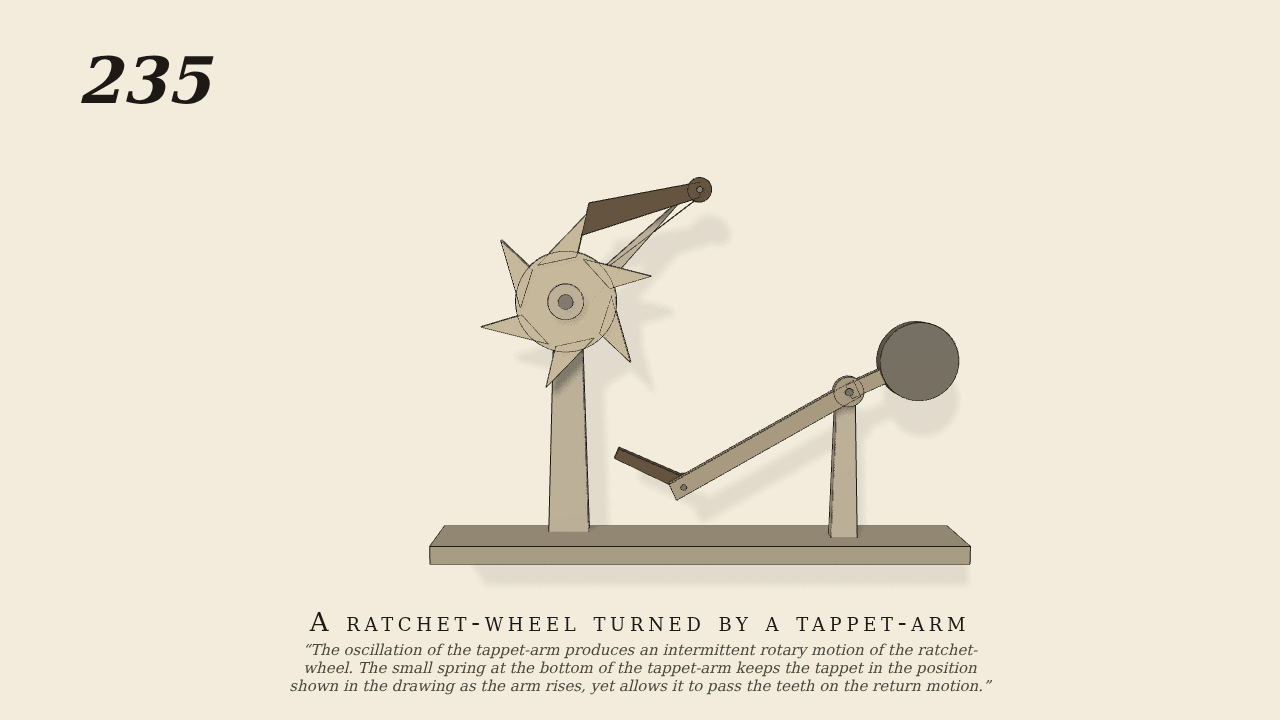
The oscillation of the tappet-arm produces an intermittent rotary…
The oscillation of the tappet-arm produces an intermittent rotary motion of the ratchet-wheel. The small spring at the bottom of the tappet-arm keeps the tappet in the position shown in the drawing as the arm rises, yet allows it to pass the teeth on the return motion.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- A ratchet-wheel of 6 teeth (tips 6, roots 3.4; radial backs, sloping fronts) on a fixed centre, with a little bearing friction, held from running back by a click above it that is pivoted on a bracket and held on a rest by its weight and a light spring. The tappet-arm, pivoted on a post to the right and balanced by a counterpoise beyond its pivot, is rocked by hand +-0.43 rad at 0.5 Hz (the only driven joint). The tappet is pinned near the arm's end. It hangs from its pin toward the wheel along a radius, and a small spring (a joint spring) holds it against a stop on the arm. Gravity on.
- Measured
- As the arm rises, the tappet's end takes a tooth by its radial back and turns the wheel counter-clockwise by a little more than a tooth. The click drops behind the next tooth, and the wheel runs back up to 0.209 rad (12 degrees, the overshoot) onto it. As the arm falls, the next tooth's slope lifts the tappet against its spring, and it passes and snaps back (5 times in 10 s). The wheel advances 0.52360 rad per beat of the arm over 8 beats (half a tooth is 0.52360), one tooth to each to-and-fro. Contact penetration 0.12 mm.
- Notes
- The plate gives no sizes. Its star has symmetric points; here the teeth have radial backs, so that the tappet and the click hold them. The tappet's path was laid out so that from mid-stroke to the top it sweeps about 70 degrees of the wheel while staying between root and tip. Without the counterpoise, the arm's weight made the hand (a velocity servo) creep downward each stroke until the tappet fell short.
Film (MP4) · Still (PNG) · Spec (YAML) · Model (MJCF)