The pinion, B, rotates about a fixed axis and gives an irregular…
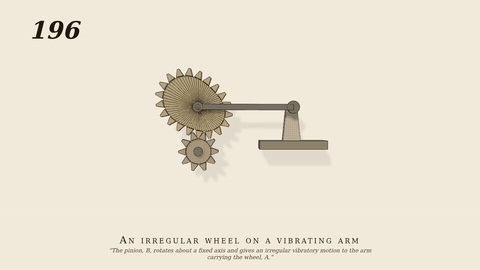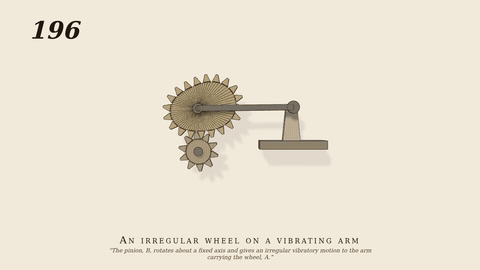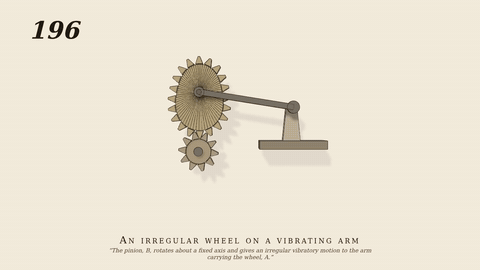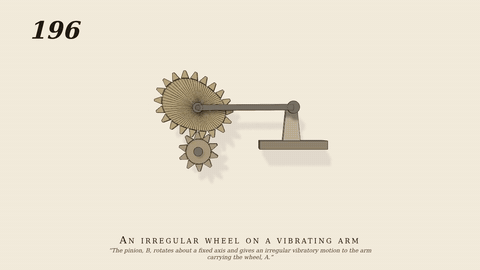
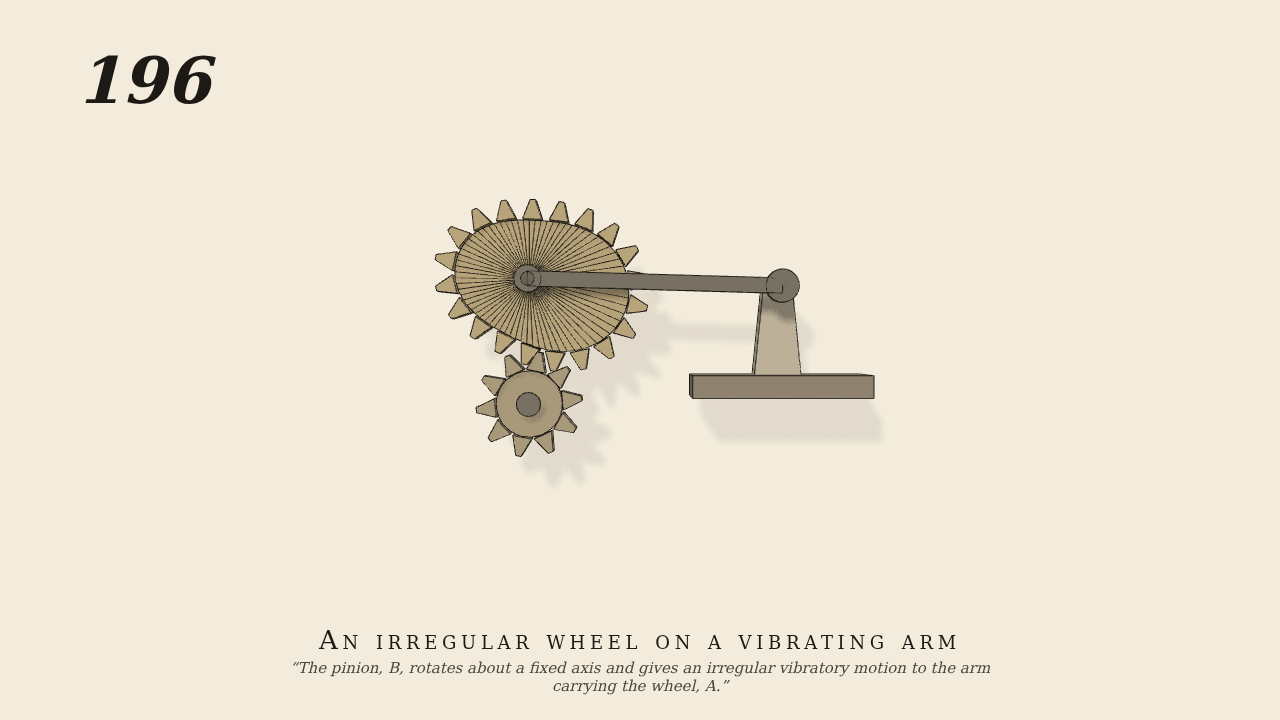
The pinion, B, rotates about a fixed axis and gives an irregular vibratory motion to the arm carrying the wheel, A.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- A 10-tooth pinion B (module 0.6, pitch radius 3) on a fixed shaft drives an irregular 20-tooth wheel A, pitch curve r = 5.83 (1 + 0.15 cos phi + 0.16 cos 2 phi) with two unequal lobes, straight-flanked teeth at equal arc pitch. A turns on a pin at the end of a 17 cm arm pivoted on a standard to the right and rests on B by its own and the arms weight, so the arm rises and falls as As radius in contact changes. A balance weight behind A puts its centre of mass on its pin. Arm angle, contact and As turning come from a rolling-kinematics solution in gen196.py.
- Measured
- Over one turn of A ratio -0.5007 (kinematic -0.5); twelfth-turn speed -0.609..-0.382 (kinematic -0.617..-0.382); arm -0.159..0.014 rad (kinematic -0.158..0.010), amplitude 4.96 deg; penetration 0.17 mm.
- Notes
- The lobes are chosen to resemble the plate; Brown gives no dimensions.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)