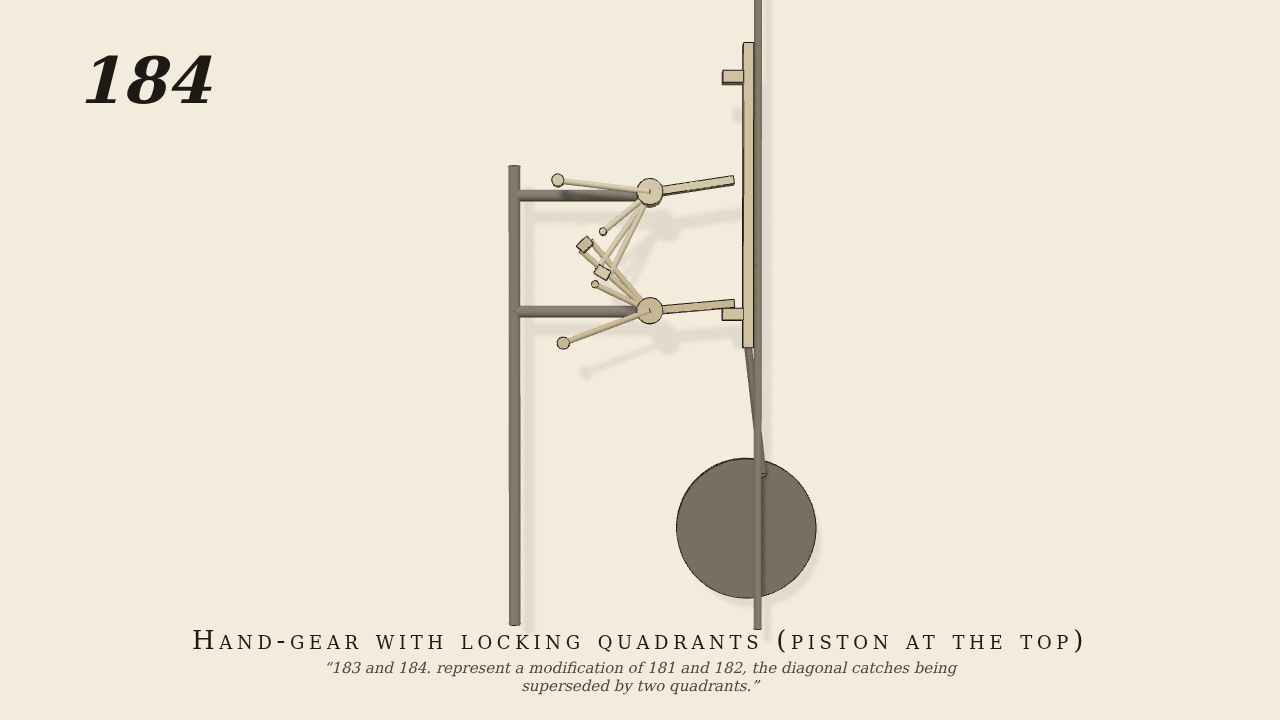
Represent a modification of 181 and 182, the diagonal catches…
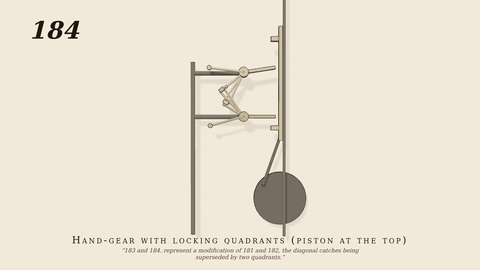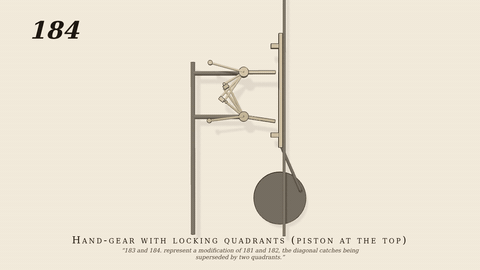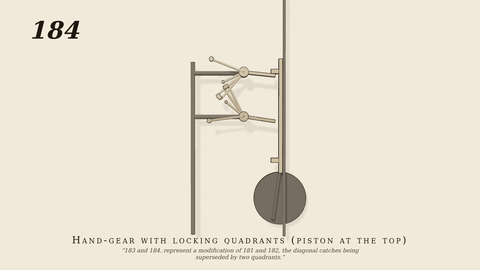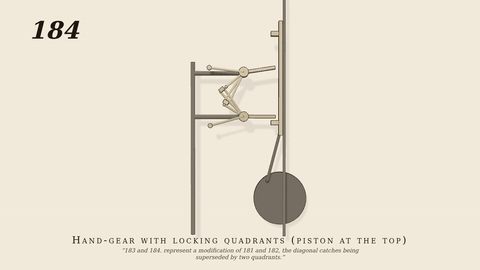
183 and 184. represent a modification of 181 and 182, the diagonal catches being superseded by two quadrants.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- The machine of No. 183 started in the state of No. 182: the lower handle held up by the upper handles quadrant and the upper handle at rest under its back-weight, the plug-rod just past the top and descending. Near the bottom tappet B throws the upper handle down: its quadrant slides from under the lower finger, the lower handle falls to rest and its quadrant swings in to hold the upper handle down; near the top tappet A throws the lower handle up and the states change back. The crank is the only driven joint (20 rpm).
- Measured
- Over 3 crank turns: after each bottom throw the upper handle is held at -0.146 rad and the lower rests at -0.150; after each top throw the lower is held at -0.003 and the upper rests at 0.000 (angles from the start pose). Max penetration 0.18 mm.
- Notes
- Same model as No. 183 (opencode-runs/batch11/gen183.py 184); valves not drawn, joint springs stand in for the back-weights.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)