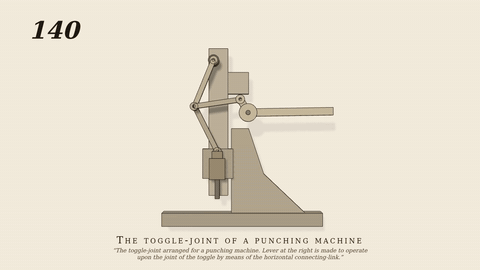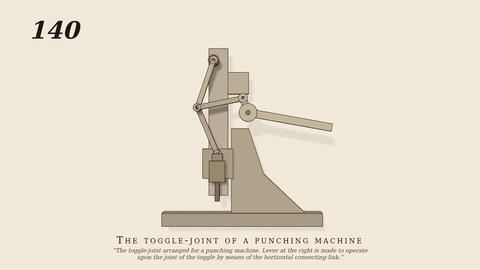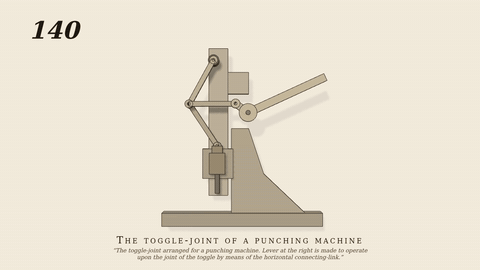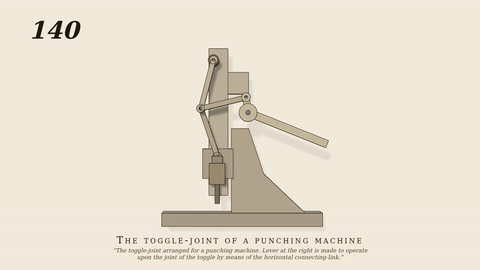
The toggle-joint arranged for a punching machine
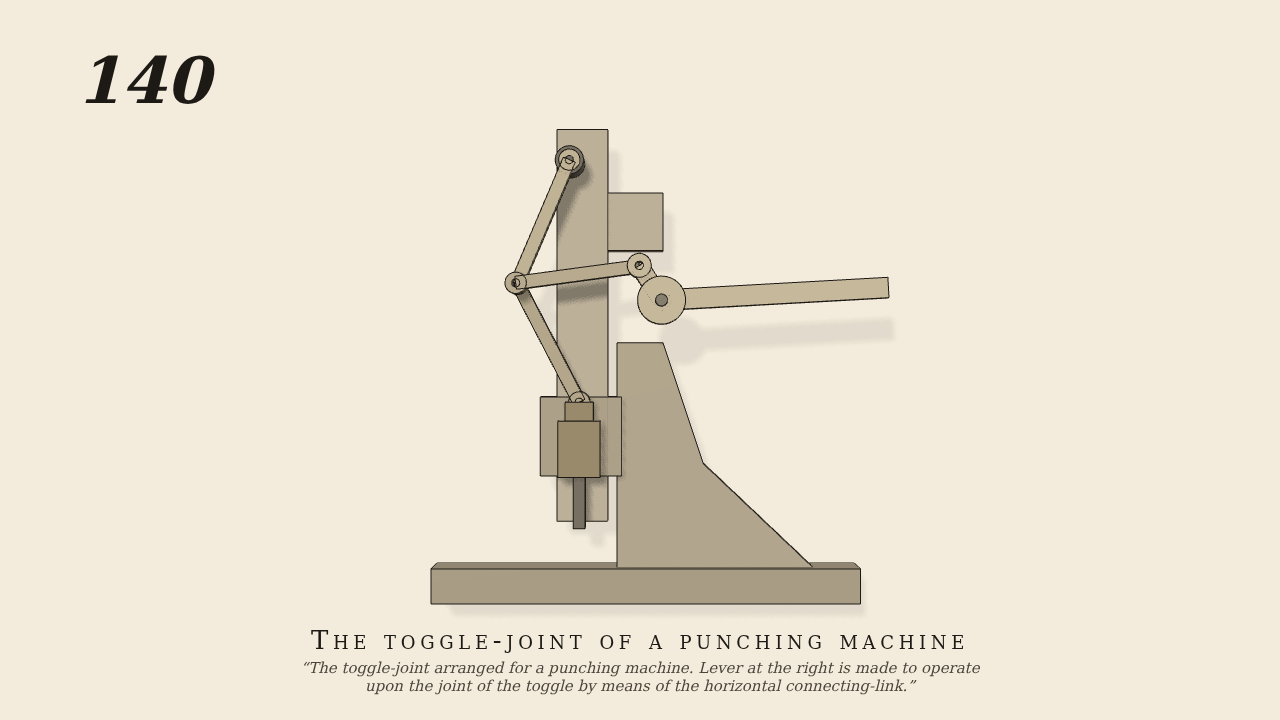
The toggle-joint arranged for a punching machine. Lever at the right is made to operate upon the joint of the toggle by means of the horizontal connecting-link.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- A bent lever at the right is swung by the hand (the one driven joint, 0.2 Hz, ±24 degrees). A horizontal connecting link joins the lever to the knee of a two-link toggle: the upper link hangs from a fixed pin on the column, the lower link pushes the punch down its guide. As the toggle straightens the punch slows and presses harder: gen140.py.
- Measured
- The punch follows the kinematic solution of the linkage in six windows spread over the swing: slopes -0.0281 / -0.0273 / -0.0282 / -0.0306 / -0.0250 / -0.0294 m per rad of the lever (expect -0.0281 / -0.0277 / -0.0276 / -0.0302 / -0.0260 / -0.0301, r2 0.999 or better); stroke -1.18..+1.21 cm. Lever amplitude 25.4 degrees.
- Notes
- Without gravity (a plan). The two loop-closing pins (knee and punch) are real pins; the swing driver has a small overshoot, so the amplitude limit is a little wide.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)