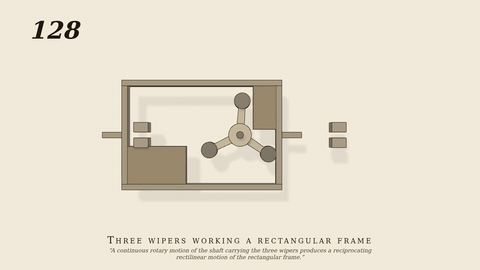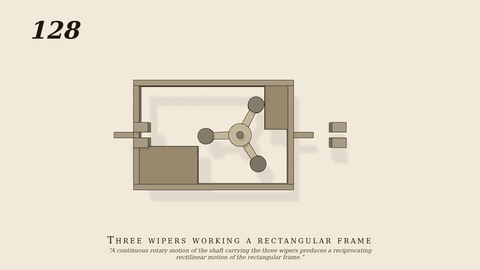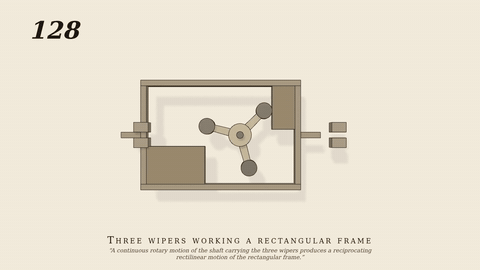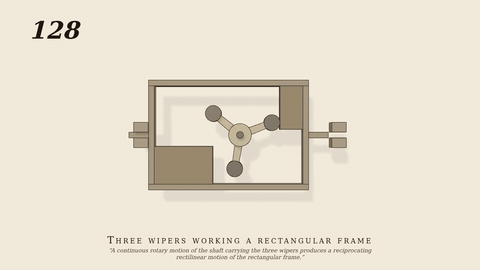
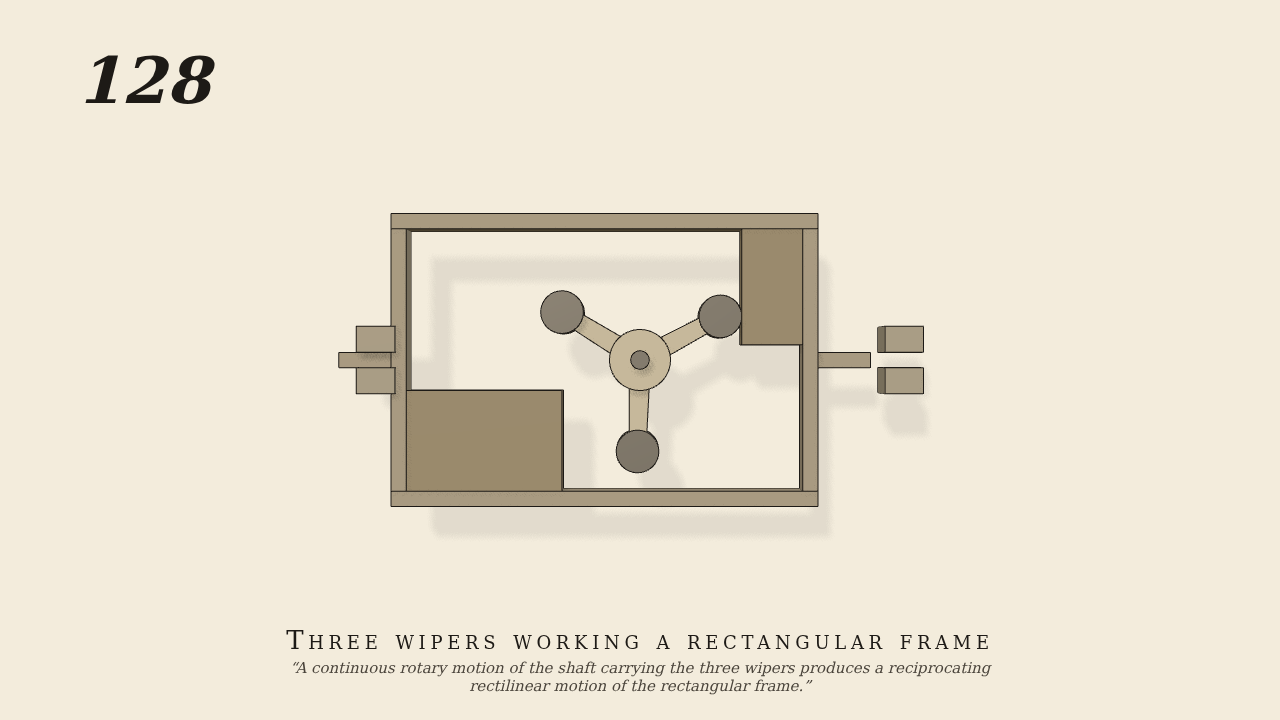
A continuous rotary motion of the shaft carrying the three wipers…
A continuous rotary motion of the shaft carrying the three wipers produces a reciprocating rectilinear motion of the rectangular frame. The shaft must revolve in the direction of the arrow for the parts to be in the position represented.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- A shaft carrying three wipers (arms of 6 cm with rollers of 1.4 cm radius, 120 degrees apart) is the only driven joint, turning clockwise at 12 rpm. Round it a rectangular frame slides to and fro on its two lugs. A block on the bottom of the frame takes the roller going left across the bottom and is pushed left by it; a block hanging from the top takes the roller going right across the top and is pushed back. The frame has friction on its guides but no spring. gen128.py.
- Measured
- Three to-and-fro strokes to a turn: the frame passes mid-stroke every sixth of a turn (1.0472 rad between, exact to 2%). Stroke -1.53 to +1.55 cm in steady running, with a dwell between pushes. Penetration 0.05 mm after the first second (7 mm as the first roller settles at the start).
- Notes
- Continuous rotation of the wipers gives a reciprocating motion with rests, three strokes a turn, in the direction of turning shown by the arrow (clockwise).
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)