A contrivance for a self-reversing motion
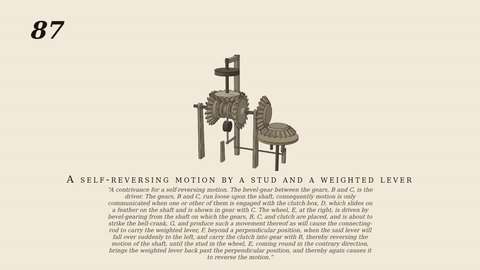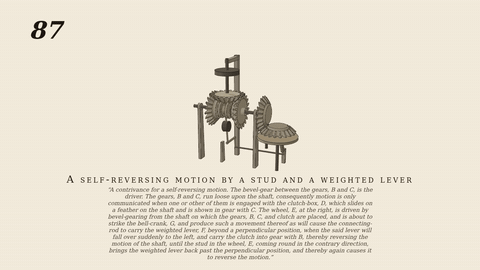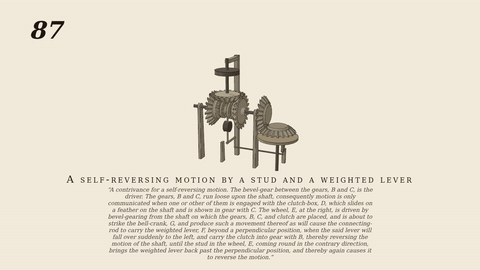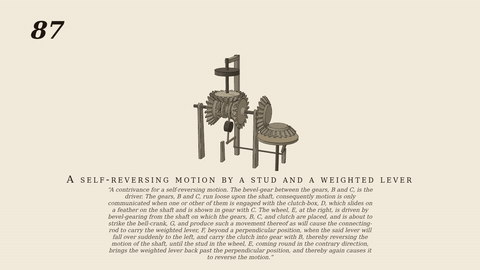
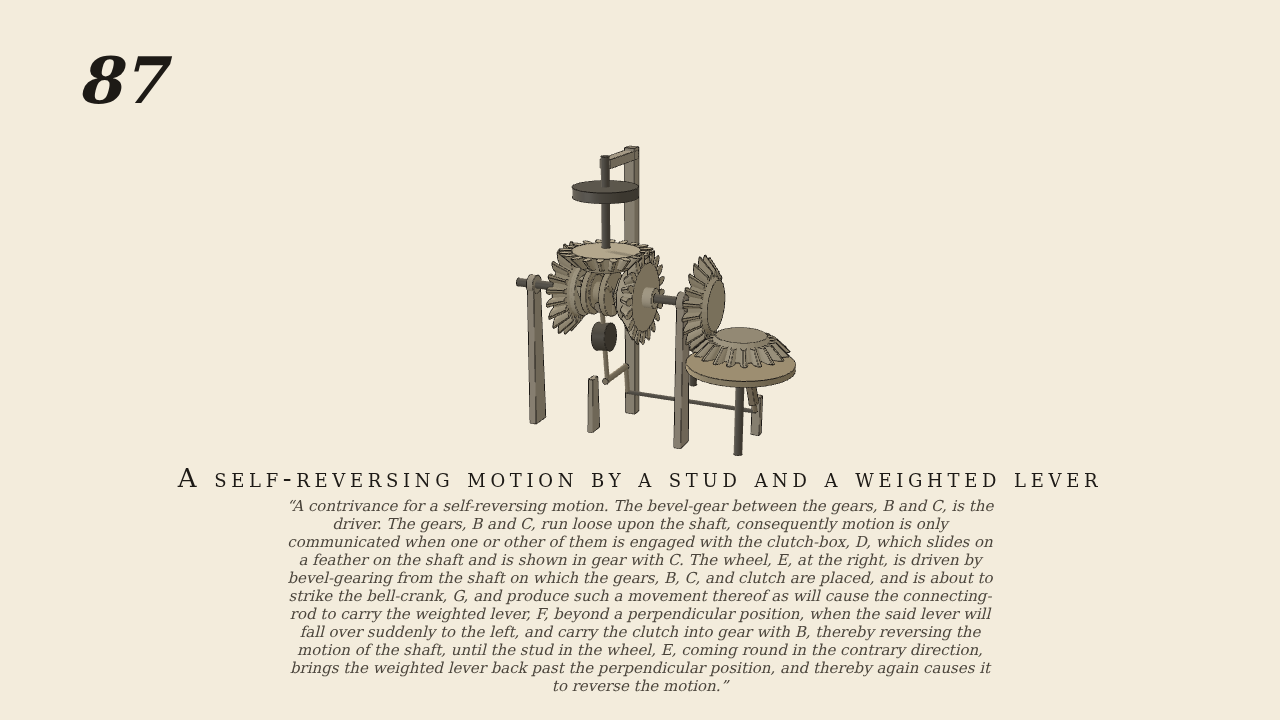
A contrivance for a self-reversing motion. The bevel-gear between the gears, B and C, is the driver. The gears, B and C, run loose upon the shaft, consequently motion is only communicated when one or other of them is engaged with the clutch-box, D, which slides on a feather on the shaft and is shown in gear with C. The wheel, E, at the right, is driven by bevel-gearing from the shaft on which the gears, B, C, and clutch are placed, and is about to strike the bell-crank, G, and produce such a movement thereof as will cause the connecting-rod to carry the weighted lever, F, beyond a perpendicular position, when the said lever will fall over suddenly to the left, and carry the clutch into gear with B, thereby reversing the motion of the shaft, until the stud in the wheel, E, coming round in the contrary direction, brings the weighted lever back past the perpendicular position, and thereby again causes it to reverse the motion.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- The upright shaft is the only driven joint; its bevel-gear drives the gears B and C, which run loose on the horizontal shaft in opposite senses (real tooth contact). The clutch-box D slides on a feather on the shaft and is put into gear with B or C by the fork of the weighted lever F. The shaft drives the wheel E by bevel-gearing; E carries a stud that, coming round, strikes the bell-crank G, whose connecting-rod carries F past the perpendicular, so that F falls over by its weight and throws D into the other gear; the shaft and E reverse, until the stud comes round the other way and strikes G again.
- Measured
- Shaft/upright ratio +0.9997, -1.0008, +0.9998, -1.0002 over the four steady phases (2.3-3.6, 5.5-8.5, 10-13, 15.3-18.3 s); E swings between -2.99 and +2.92 rad and never goes round; gears A, B at -1.0003, +0.9998. Max penetration 0.10 mm.
- Notes
- Reversal is by real contact (stud on G, fork on the clutch, clutch jaws); each reversal takes about 1 s while F falls and the jaws find their slots. F weight and joint damping only; the rod is pinned.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)