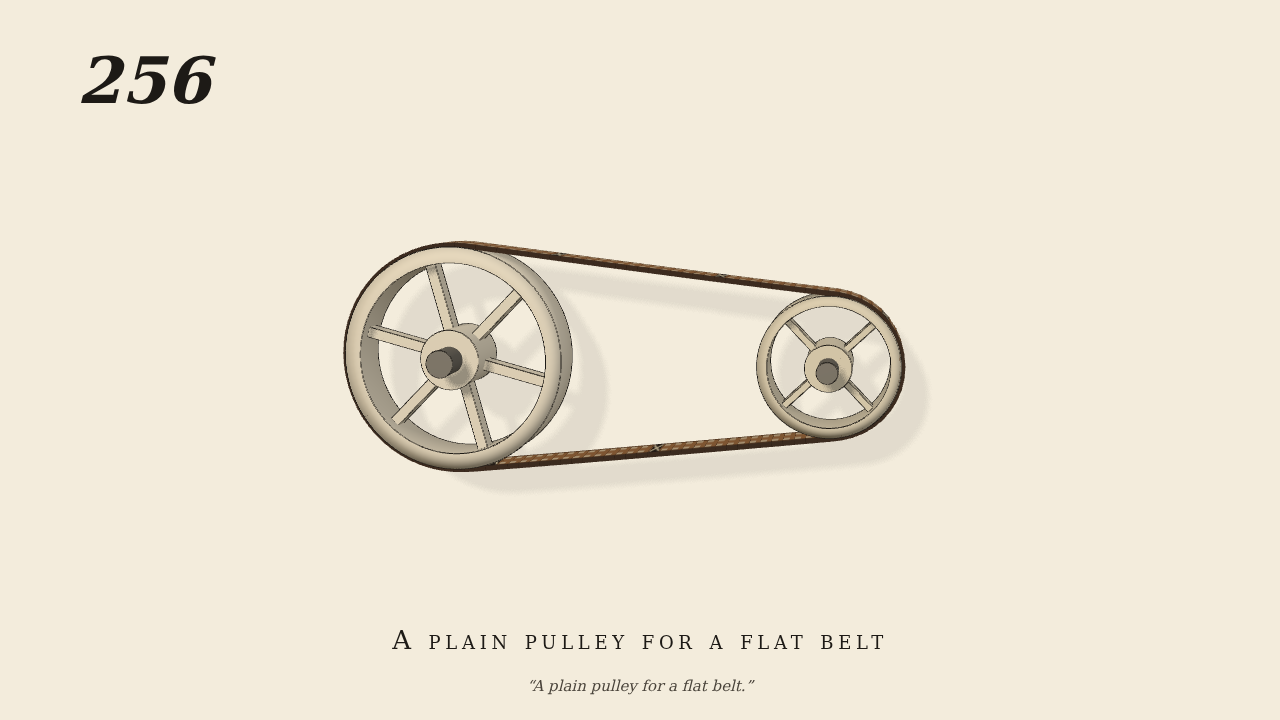
A plain pulley for a flat belt
A plain pulley for a flat belt.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- Front view, shafts level, gravity on. Two plain pulleys (no flanges, faces 4 cm wide). The larger (radius 9 cm) is on the driving shaft, turned at 40 rpm (the one driven joint). The smaller (radius 5.5 cm), 30 cm away, carries a load (a damper). A tensioned flat belt of links on real contact lies on the plain faces and drives the smaller by friction.
- Measured
- The small pulley turns at 1.5936 times the large one's speed against 1.6140 from the pitch radii, r + 0.2 (slip 1.3%), over 1 to 5.5 s. The belt stays on the plain faces (radial deviation 0.23 cm, lateral 0). The deepest contact is 1.4 mm, inside the belt's soft contact.
- Notes
- Brown gives no sizes. With the shafts true the belt keeps its place on the plain faces without flanges.
Film (MP4) · Still (PNG) · Spec (YAML) · Model (MJCF)