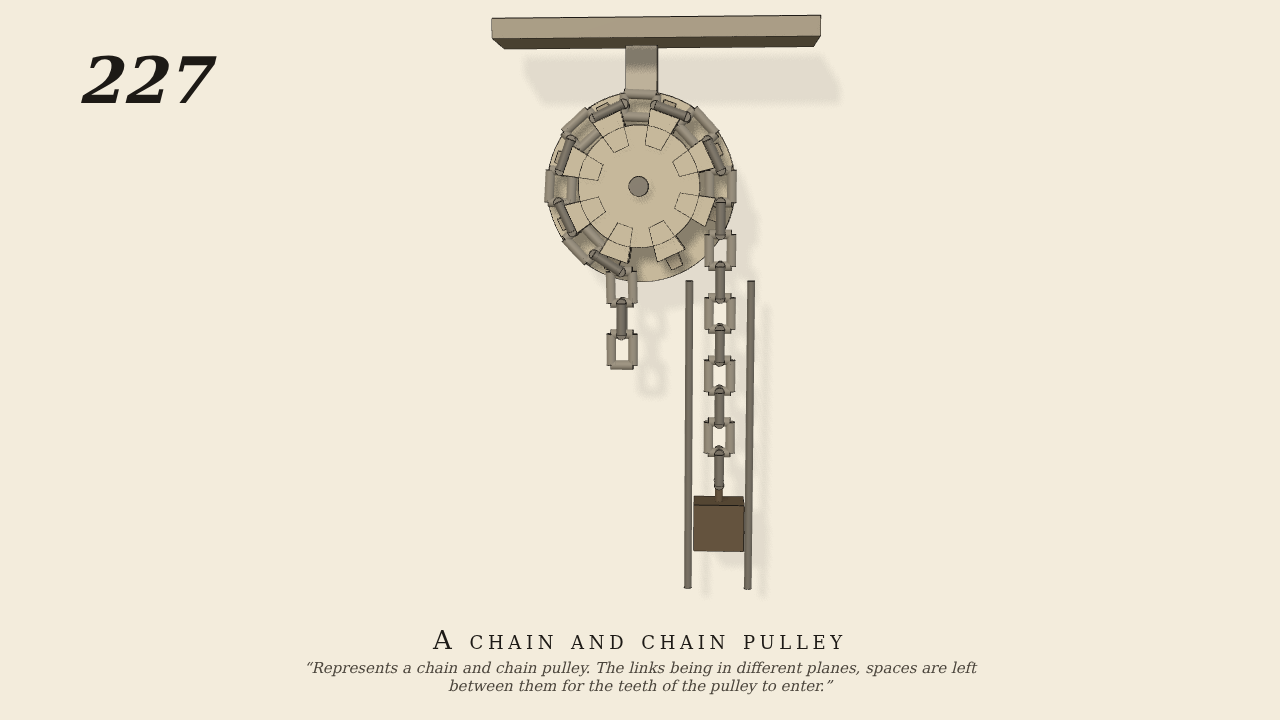
A chain and chain pulley
Represents a chain and chain pulley. The links being in different planes, spaces are left between them for the teeth of the pulley to enter.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- An open-link chain (pitch 2, rods radius 0.3) hangs over a pulley that is a 16-sided polygon. The flat links lie in seats on alternate faces of the pulley. On the faces between them a tooth stands up through the space inside each edge link (the links in the other plane), and it bears on the end of the next flat link. The right-hand end carries a 0.4 kg weight running in vertical guides and the left end hangs free (gravity on). Only the pulley is driven (4 rpm, counter-clockwise). The links are hinged to each other and the chain is held on the pulley by its seats and teeth alone.
- Measured
- The weight rises 0.0510 m per radian of the pulley (expect 0.0509, the pitch radius of the 16-sided chain path), r-squared 1.0000. Max penetration 0.03 mm.
- Notes
- The plate gives no sizes. The pulley has 8 seats and 8 teeth; the chain path radius is 5.126.
Film (MP4) · Still (PNG) · Spec (YAML) · Model (MJCF)