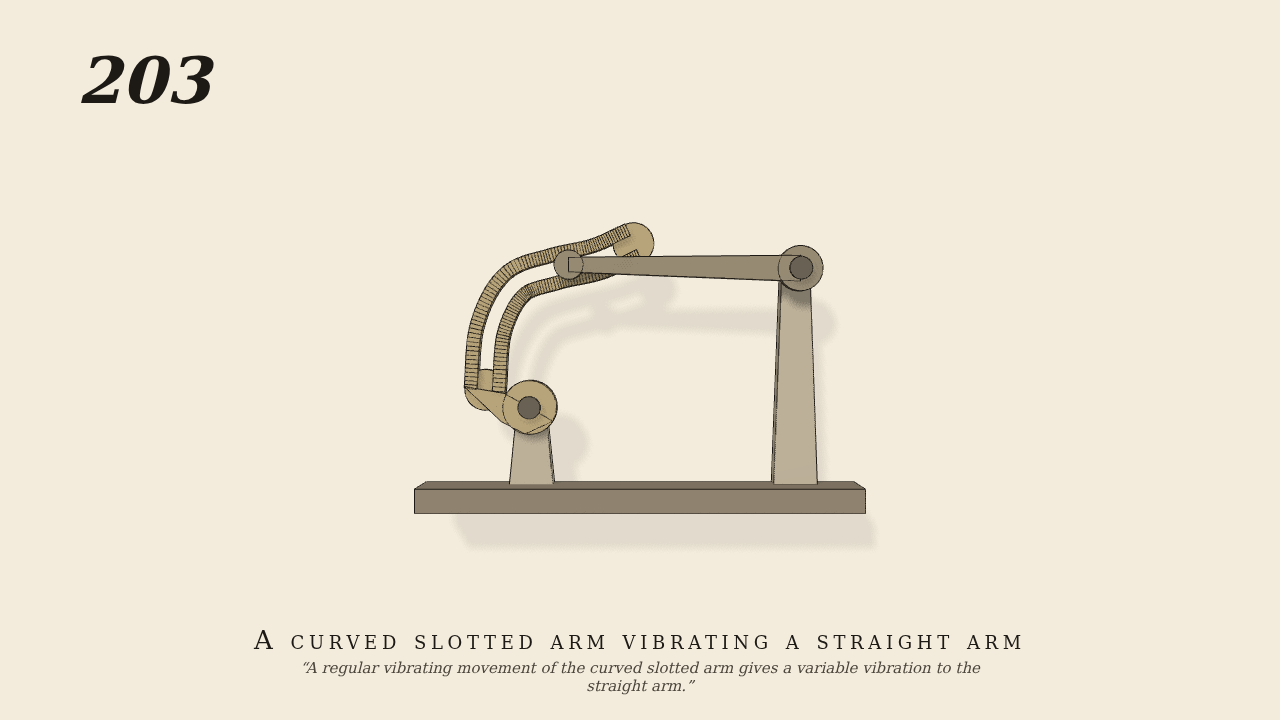
A regular vibrating movement of the curved slotted arm gives a…
A regular vibrating movement of the curved slotted arm gives a variable vibration to the straight arm.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- Laid out after the plate: the curved arm turns on a pivot at the lower left and is the only driven joint, rocked evenly by hand (+-0.32 rad at 0.4 Hz). Its slot runs from low on the left up and over to the upper right. The straight arm is pivoted 17 cm to the right, and the pin at its free end (14.45 cm out) works in the slot with 0.04 cm clearance. The slot's slant to the curved arm's radius changes along it, so the straight arm's leverage changes as the pin travels.
- Measured
- The straight arm swings -0.170 to +0.078 rad (want -0.176 / +0.073), lopsided for an even drive. Its rate to the curved arm runs -0.97 to -0.19 in sixteenths of two cycles (kinematics -1.13 to -0.18). Max penetration 0.01 mm after 1 s.
- Notes
- Gravity is on: the straight arm's weight rests the pin on the slot's lower side. Its joint has stops at -0.3 and +0.2 rad, which it never reaches in work; they hold it when the pin is out for the negative control.
Film (MP4) · Still (PNG) · Spec (YAML) · Model (MJCF)