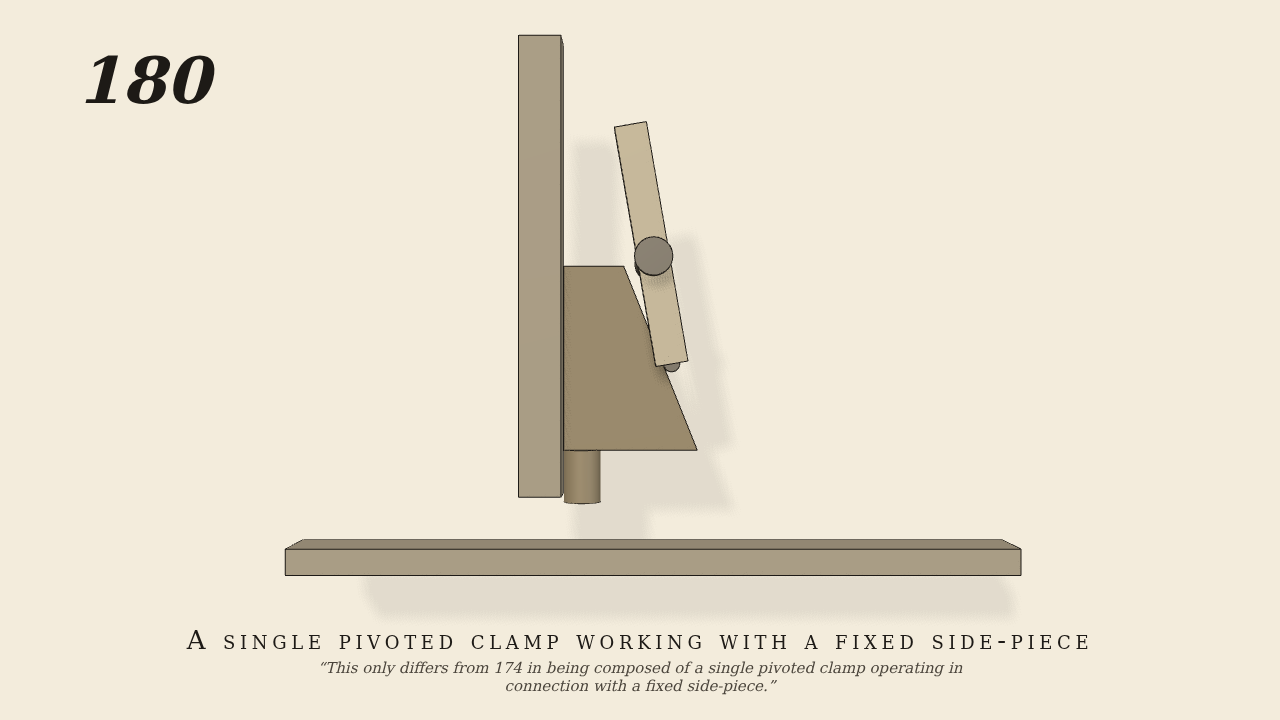
This only differs from 174 in being composed of a single pivoted…
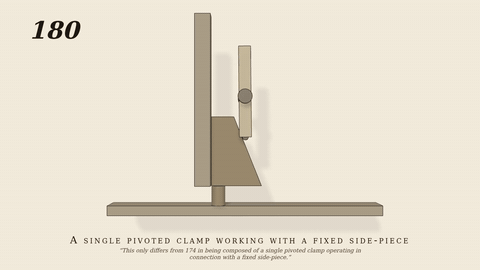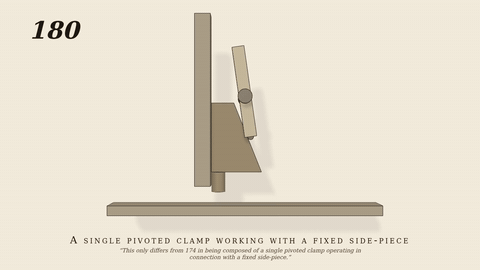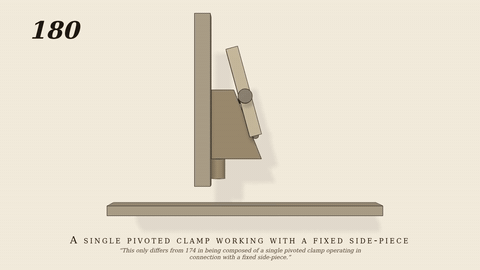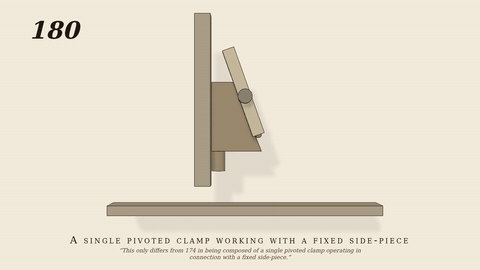
This only differs from 174 in being composed of a single pivoted clamp operating in connection with a fixed side-piece.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- The wedge-shaped clamp (the one driven joint, a slide pushed up at 0.7 cm/s) goes between the 4 cm mouth end of one pivoted jaw and the fixed side-piece. The jaw turns on its screw by real contact of its mouth pin on the wedge face (taper 0.4), and its 5 cm far end closes toward the side-piece to grip the work. No gravity (a plan). gen180.py (MODE=180).
- Measured
- The jaw follows the clamp at 9.68, 9.47 and 9.34 rad/m in three windows (kinematic the same, r2 1.000). The clamp goes 3.35 cm, the jaw turns 18 degrees and its far end closes 1.6 cm. Penetration 0.
- Notes
- The jaw has no spring; the wedge only advances, so the contact holds. The work is not drawn.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)