Contrivance for uncoupling engines
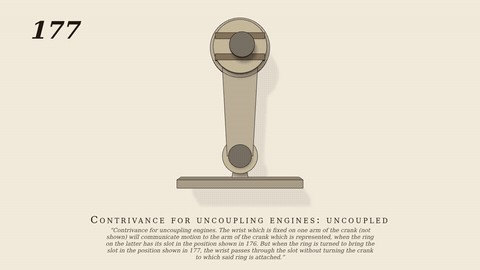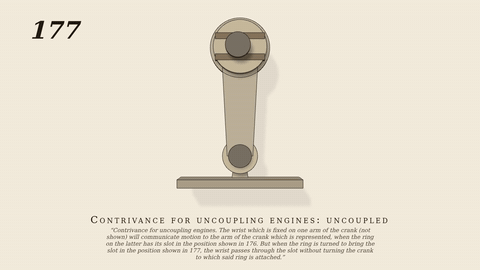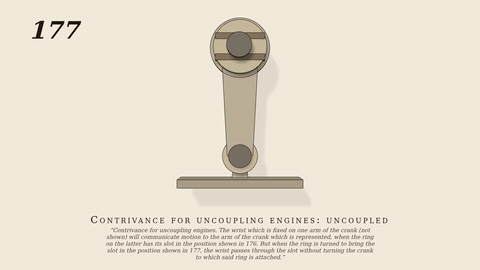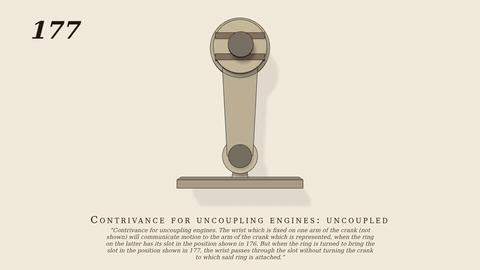
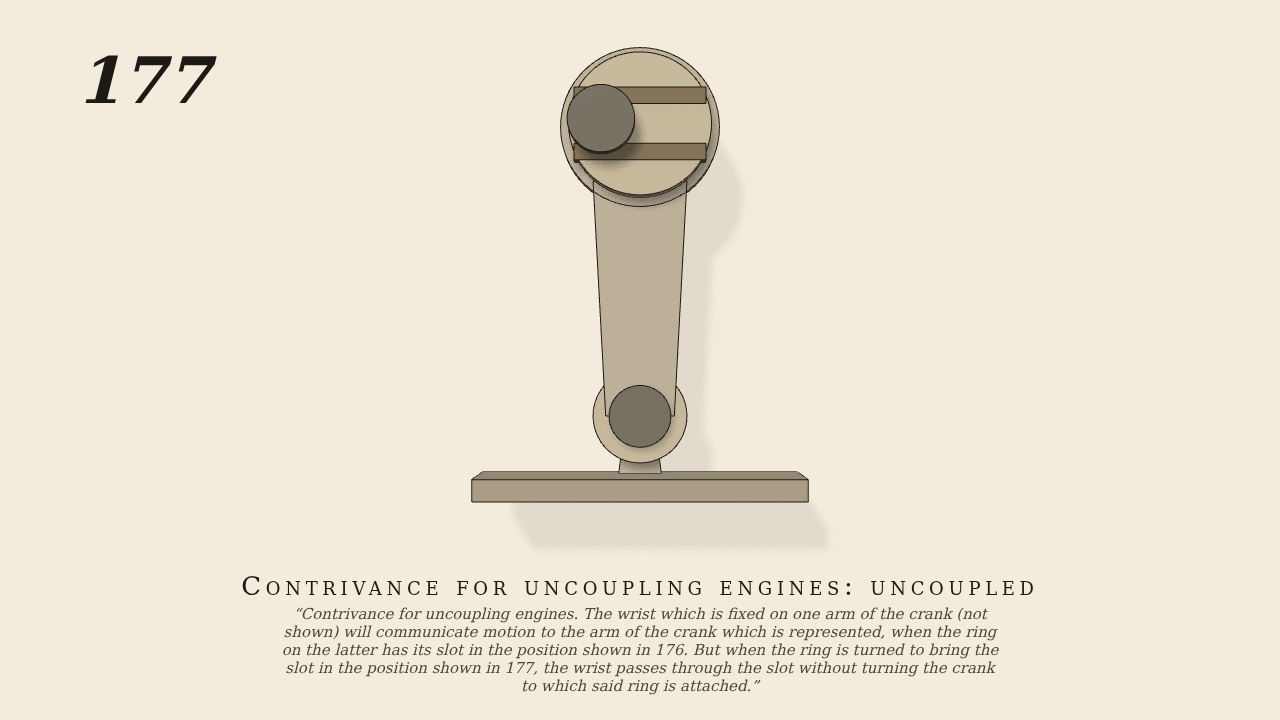
176 and 177. Contrivance for uncoupling engines. The wrist which is fixed on one arm of the crank (not shown) will communicate motion to the arm of the crank which is represented, when the ring on the latter has its slot in the position shown in 176. But when the ring is turned to bring the slot in the position shown in 177, the wrist passes through the slot without turning the crank to which said ring is attached.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- The ring in the head of the crank arm is turned a quarter turn from 176, so its slot lies along the wrist's path. The wrist (the one driven joint, a slide moving 2.8 cm either way, a quarter turn a second) runs along the slot between its walls (0.08 cm clearance) without touching them. The arm hangs on a pivot 16 cm below. No gravity. gen176.py (MODE=177).
- Measured
- The wrist runs the full 2.8 cm either way and the crank arm stands still: mean speed below 0.02 rad/s, position within +-0.01 rad for the whole run. Penetration 0.
- Notes
- Reading of the figure: the only difference from 176 is the slot position; the arm is damped like 176. Control is the same machine as 176 (whose control removes the walls so that the arm stands); here the arm already stands, so no stall control exists.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)