Reciprocating rectilinear motion into intermittent circular motion…
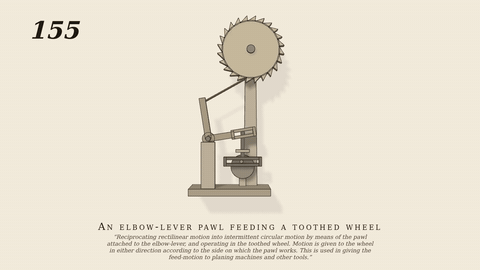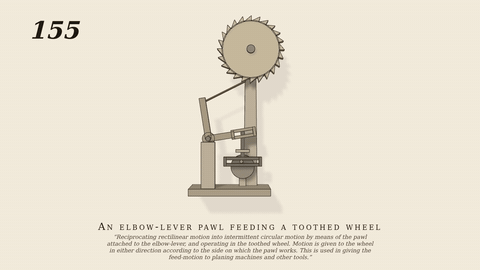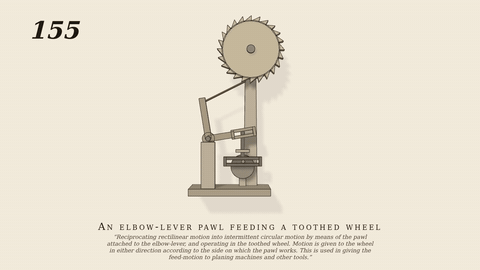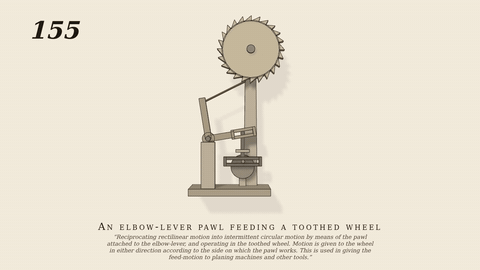
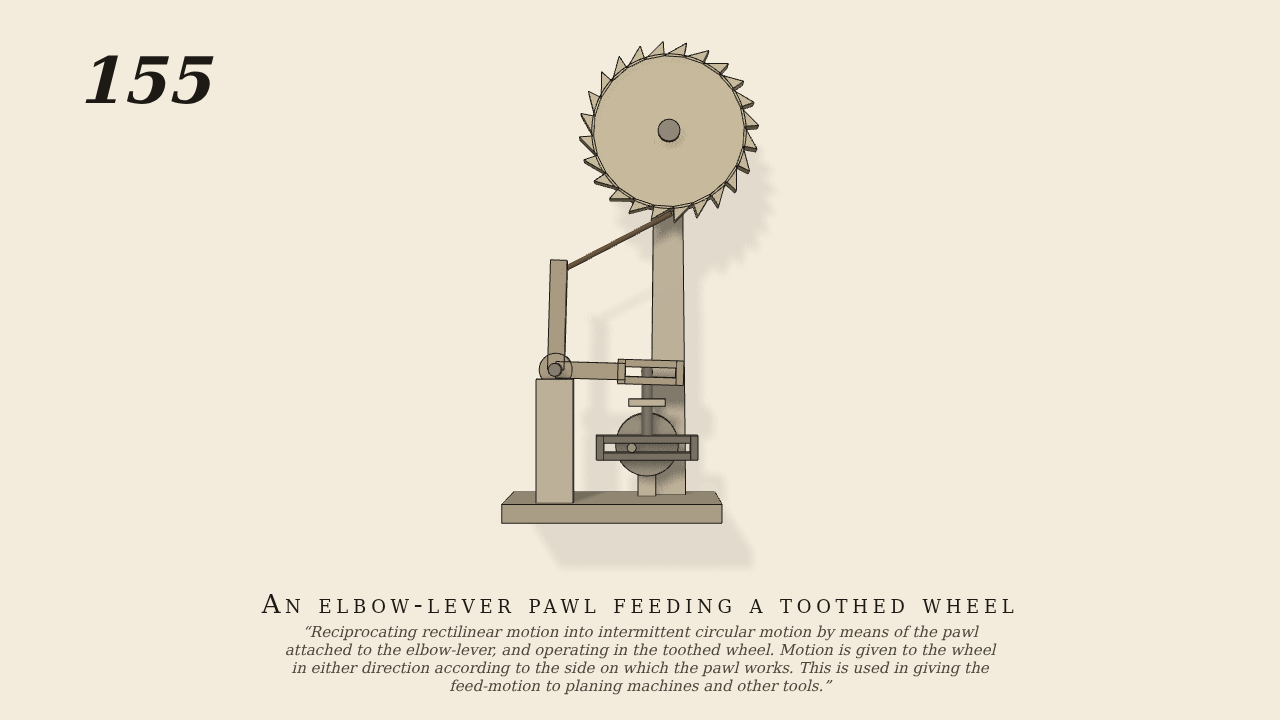
Reciprocating rectilinear motion into intermittent circular motion by means of the pawl attached to the elbow-lever, and operating in the toothed wheel. Motion is given to the wheel in either direction according to the side on which the pawl works. This is used in giving the feed-motion to planing machines and other tools.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- A crank (the one driven joint, 30 rev/min) works a slotted yoke on a rod C, which slides 1.7 cm up and down; the rod pin works in the slot of one arm of an elbow-lever and the other arm carries a sprung pawl that lies on the lower side of a 24-tooth ratchet wheel. As the rod falls the pawl pushes a tooth on; as it rises the pawl rides back over a tooth and drops behind it: gen155.py.
- Measured
- The wheel turns 1/24 of a turn per crank turn (ratio 0.0417 against 0.0417, slip -0.03%), one tooth every double stroke and never backwards; the pawl clicks over 10 teeth in 10 s. Penetration 0.12 mm.
- Notes
- Plain contact throughout: the pawl against the teeth (friction 0.4 on the pawl), the rod pin in the lever slot and the crank pin in the yoke. Worked on the other side of the wheel (the mirror image) the pawl would turn it the other way.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)