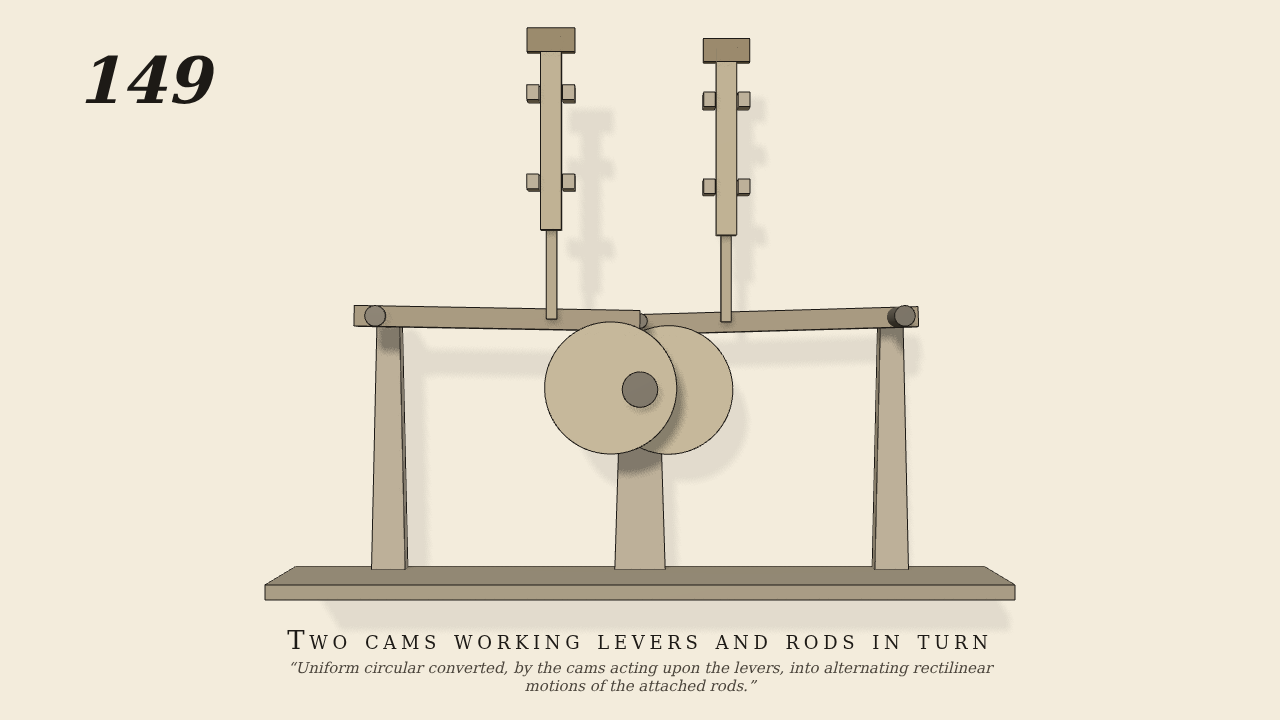
Uniform circular converted, by the cams acting upon the levers,…
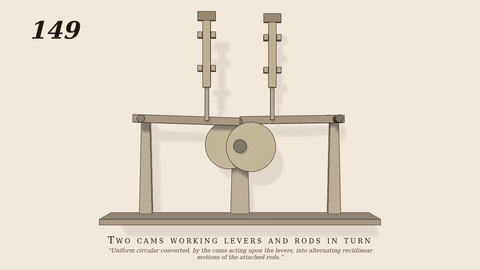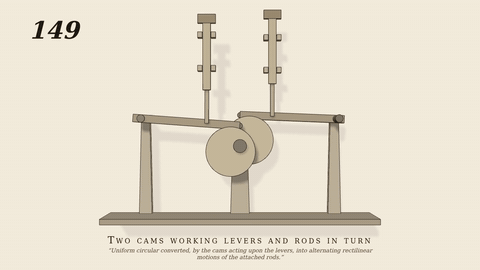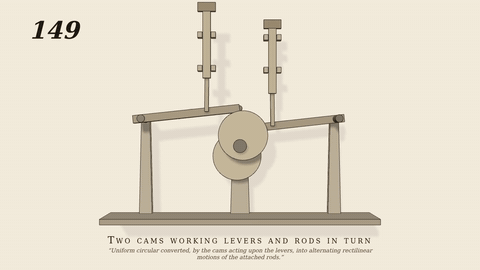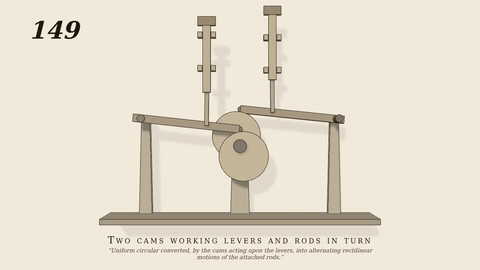
Uniform circular converted, by the cams acting upon the levers, into alternating rectilinear motions of the attached rods.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- One shaft (the one driven joint, 12 rev/min) carries two eccentric cams (4.5 cm radius, 2.0 cm throw) set half a turn apart. A lever on each side, pivoted on its standard, rests its finger on its cam by its own weight; a link from a point 12 cm along each lever lifts and lowers a vertical rod in its guides, so the rods move alternately in a straight line: gen149.py.
- Measured
- Each rod follows the shaft in straight stretches of the stroke: slopes -0.0129 and +0.0127 m per rad (r2 0.995 to 0.996, left and right rods, opposite in sense), stroke about 2.7 cm (-1.34 to +1.33 cm). Penetration 0.01 mm after the first second.
- Notes
- The levers are held to their cams by weight alone; the driver is a gentle velocity servo so the lever does not shake the shaft. Fingers keep clear of one another in the middle of the shaft.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)