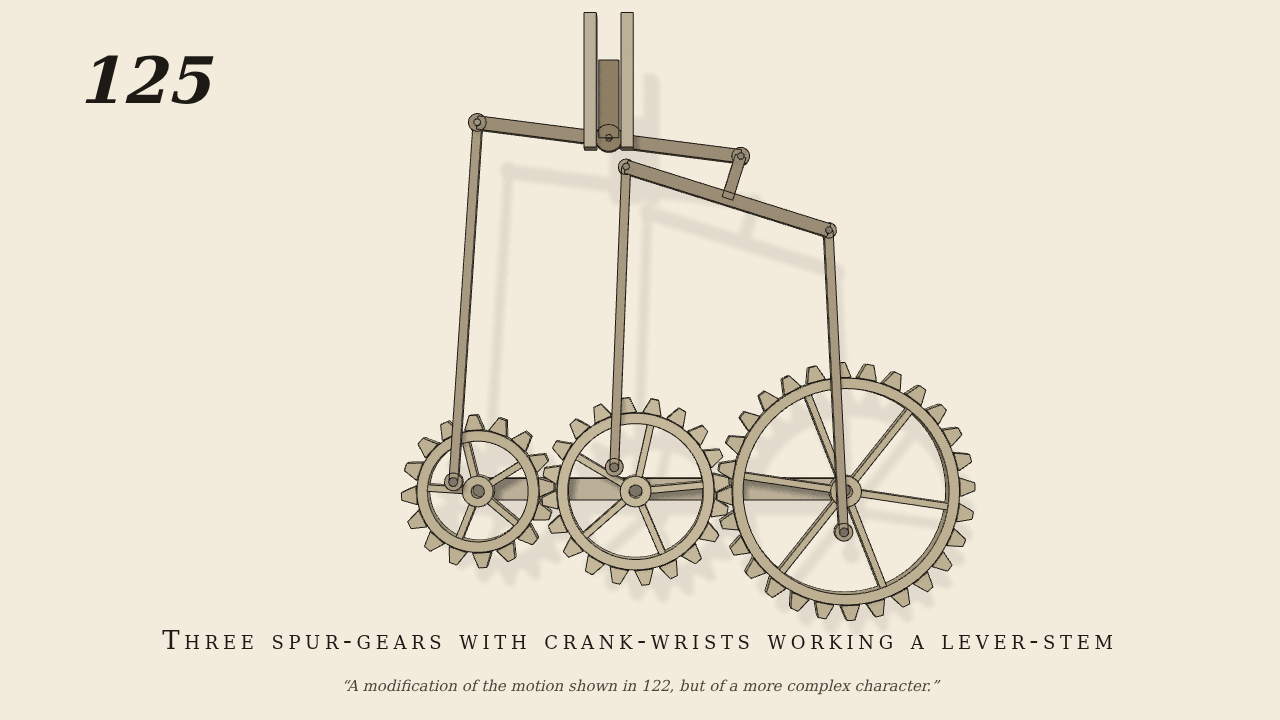
A modification of the motion shown in 122, but of a more complex…
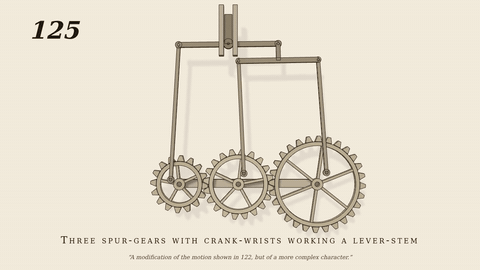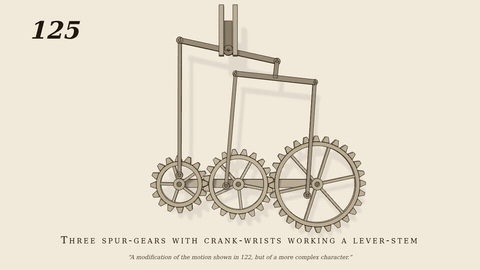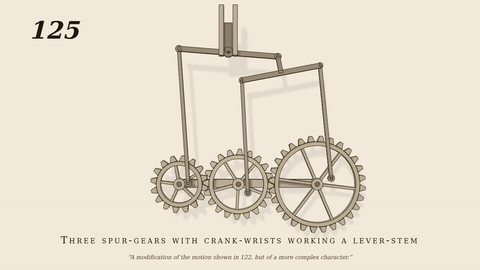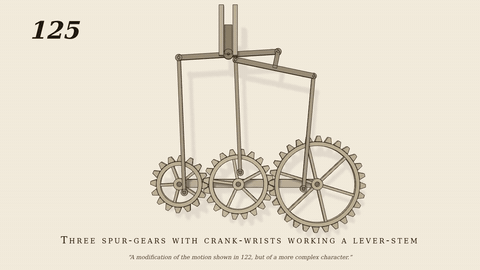
A modification of the motion shown in 122, but of a more complex character.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- Three spur-gears of 16, 20 and 28 teeth (module 0.8) mesh in a row; the middle one is the only driven joint (20 rpm) and the small and large turn the other way through their teeth. Each has a crank-wrist (2.3, 3.0 and 3.6 cm out). A rod from the small gear wrist goes to one end of the upper lever, which swings on a stem sliding in a guide; the other end of that lever is the pivot of the lower lever, whose two ends have rods to the wrists of the middle and large gears. No gravity (a plan). gen125.py.
- Measured
- Small gear/middle -1.25 and large/middle -0.714 (teeth 20:16 and 20:28). Stem against the middle gear: +0.0117, -0.0111, +0.0206 and -0.0233 m/rad in four windows (linkage kinematics +0.0117, -0.0111, +0.0206, -0.0233); the whole 12 s track agrees with the kinematics to 0.01 cm. Stroke -4.65 to +0.42 cm (5 cm) and it does not repeat in a turn. Penetration 0.03 mm.
- Notes
- The stem takes up three cranks through two levers, so its motion is the more complex one the catalog asks for: the three gears run at 5:4 and 5:7 of one another, so the stroke only repeats after 28 turns of the middle gear.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)