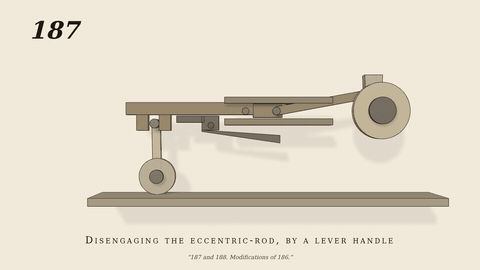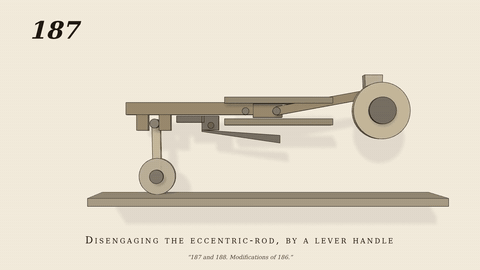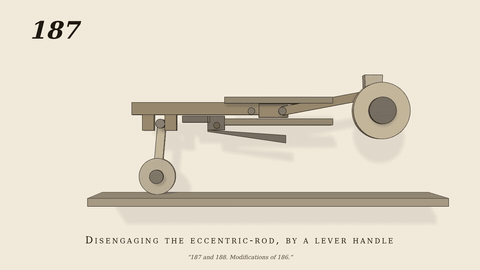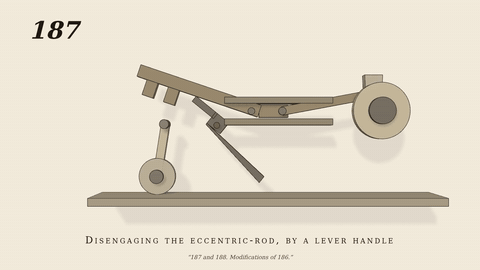
Modifications of 186.
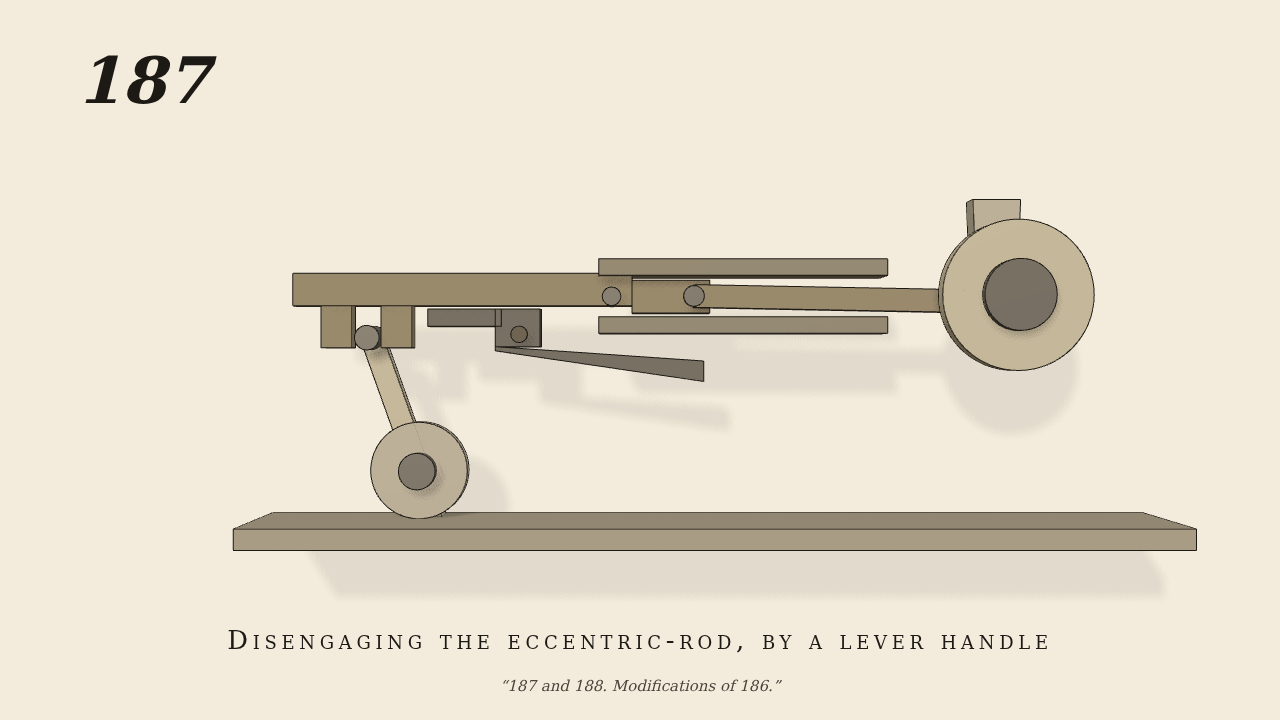
187 and 188. Modifications of 186.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- Variant of 186: the eccentric (one driven joint, 30 rpm) works the rod, whose hinged gab holds the pin of a 7 cm rock-shaft arm. A handle lever pivoted on the rod has a toe under the gab bar; at 5 s the hand-schedule pulls the handle and the toe lifts the gab by real contact, so the notch clears the pin. No gravity. gen187.py.
- Measured
- Engaged: the rock-shaft arm follows the rod at -14.47 rad/m (kinematic -14.58), r2 1.000; after the lift the gab stays up (0.33 rad) and the rock-shaft stands (0.000 rad/s) while the rod goes on; penetration 0.14 mm.
- Notes
- Putting it back is not modelled. The hand pulls the lever through its spring rest position; the catch a is the spring holding the lever.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)