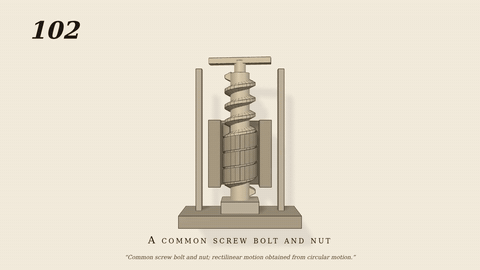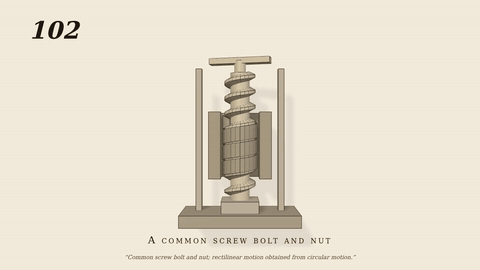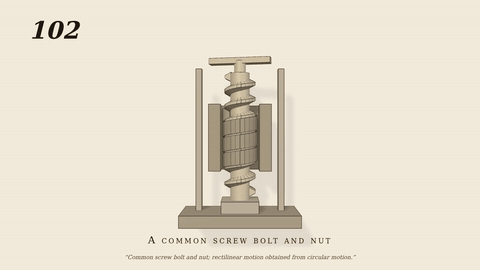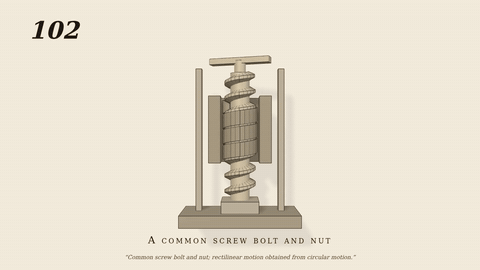
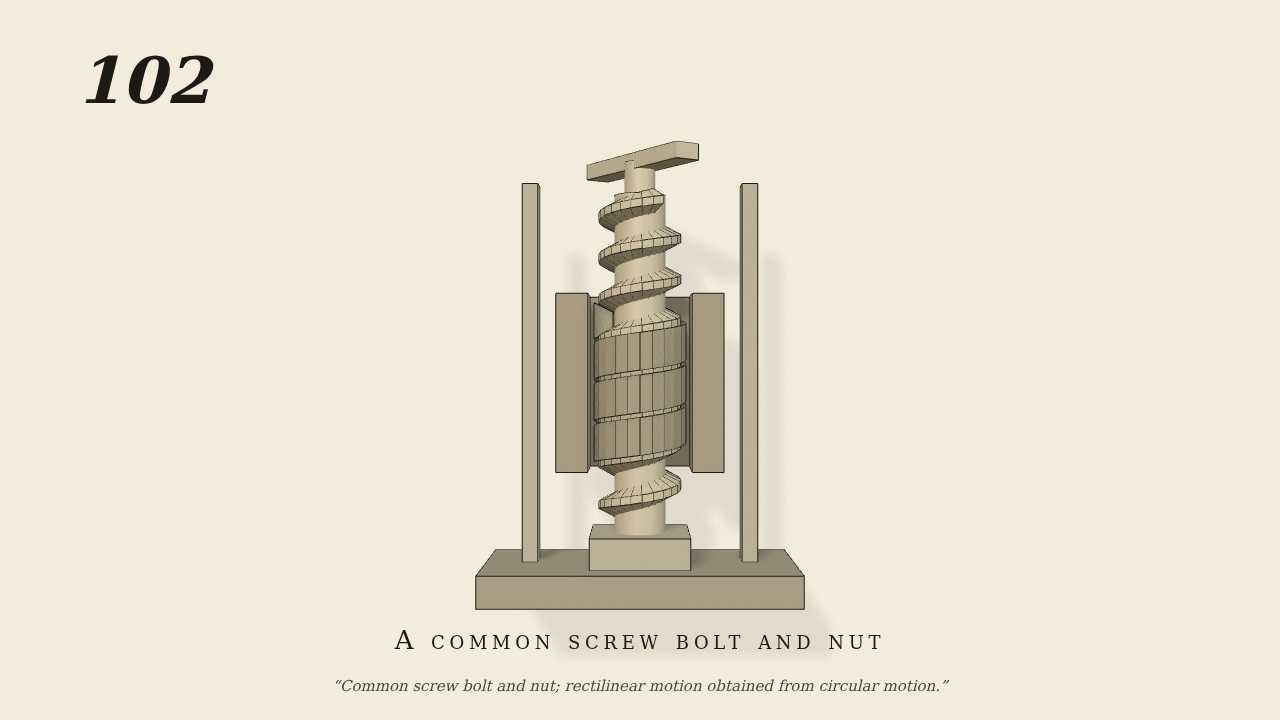
Common screw bolt and nut
Common screw bolt and nut; rectilinear motion obtained from circular motion.
Only the input is driven; every other part of this model moves by physics (MuJoCo), and its ratios are measured. Run it live, change its parameters, or switch the friction off to see the output stop.
- Modelled as
- A bolt stands upright and turns on its axis (16 rpm clockwise from above, the only driven joint): a right-hand thread of pitch 1.6 cm, 7.5 turns, a ridge 0.9 cm wide at the core (radius 1) and 0.3 at its tip (radius 1.6), laid in 24 convex segments a turn. The nut (drawn cut away at the front) can only slide up and down; its 3-turn thread fills the bolt groove with 0.04 cm clear each flank. Only the threads touch; the nuts weight keeps its lower flank on the bolts upper. Each turn lifts the nut one pitch, 1.6 cm.
- Measured
- Nut rise against the bolt: -0.0025 m/rad in both windows (ideal -0.002546 = the pitch over 2 pi; the bolt turns negative to raise the nut), r2 1.0000; net 0.0330 m over 13.03 rad = 0.00253 m/rad; rise 0.18..3.91 cm; max penetration 0.08 mm.
- Notes
- Driver servo kept soft (kv 0.3): a free bolt with a stiff servo chatters at this inertia.
Film (MP4) · GIF · Still (PNG) · Spec (YAML) · Model (MJCF)